Abstract
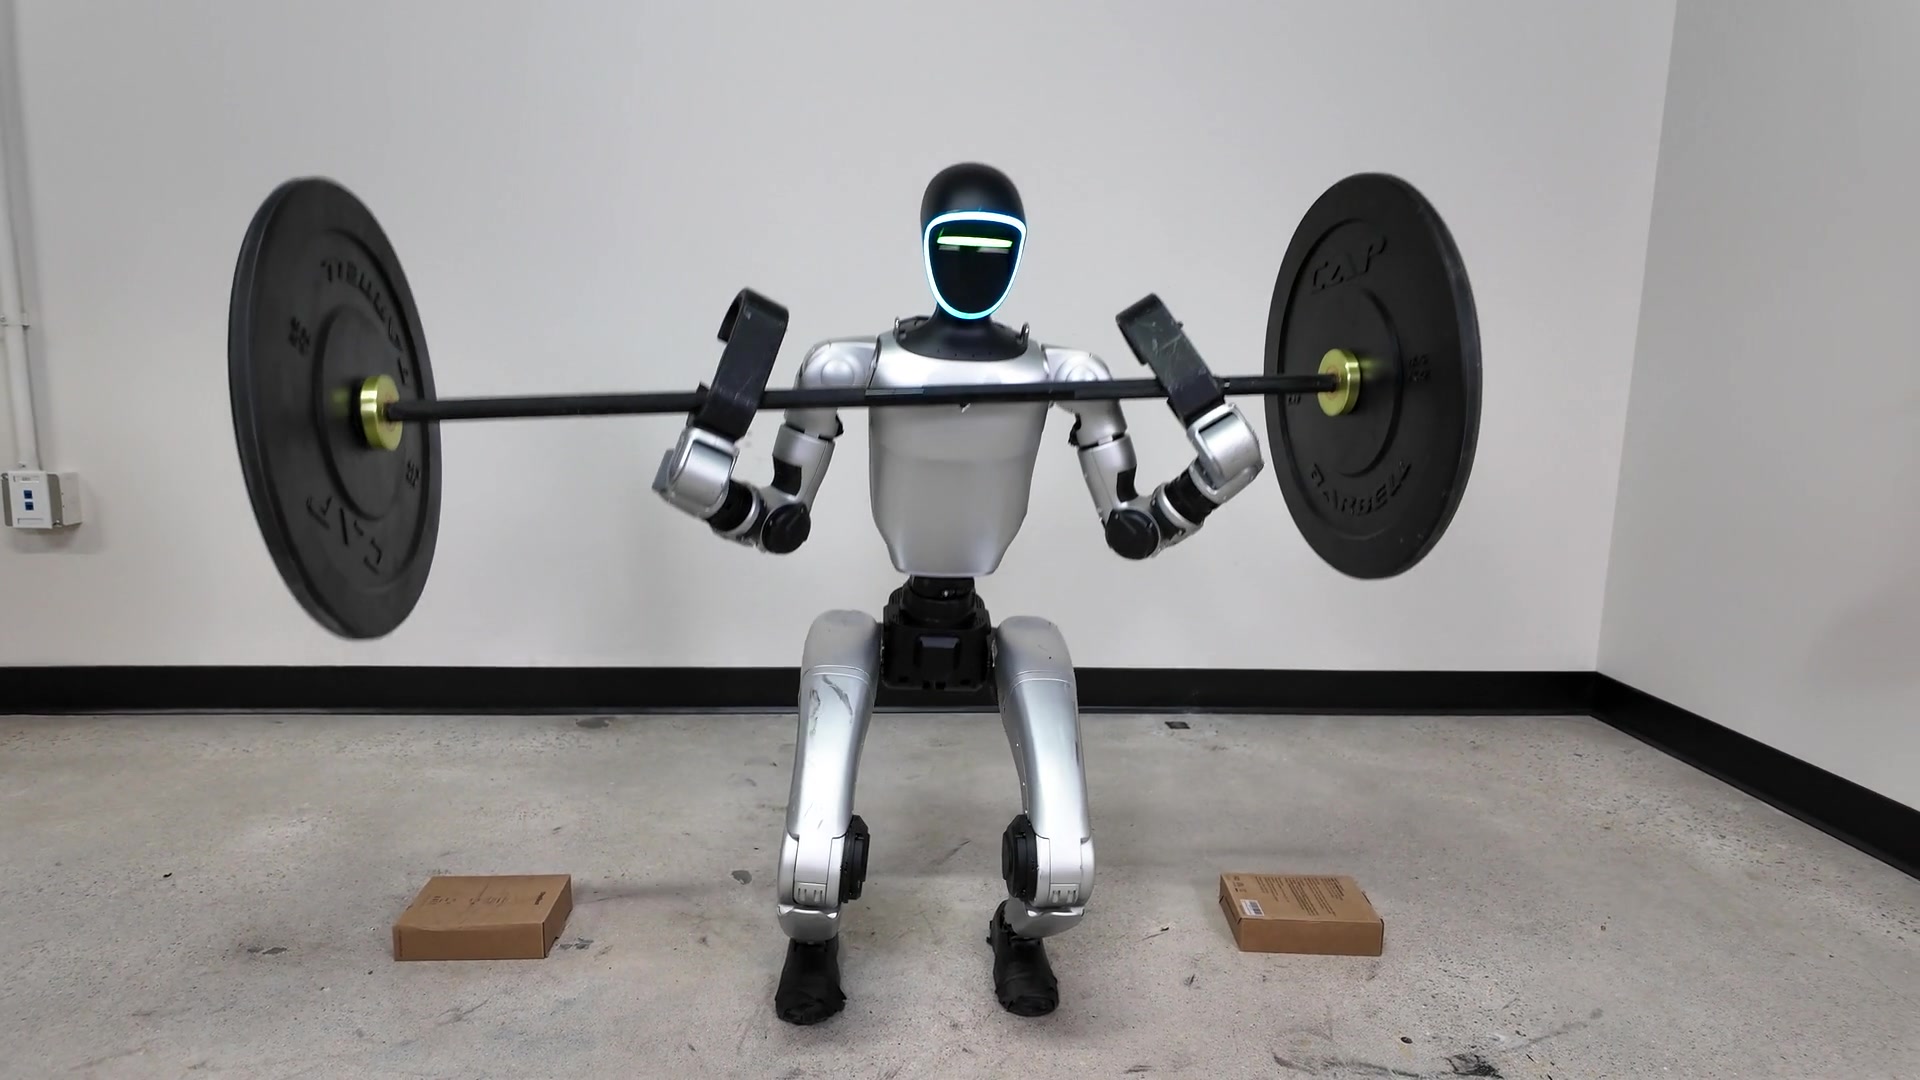
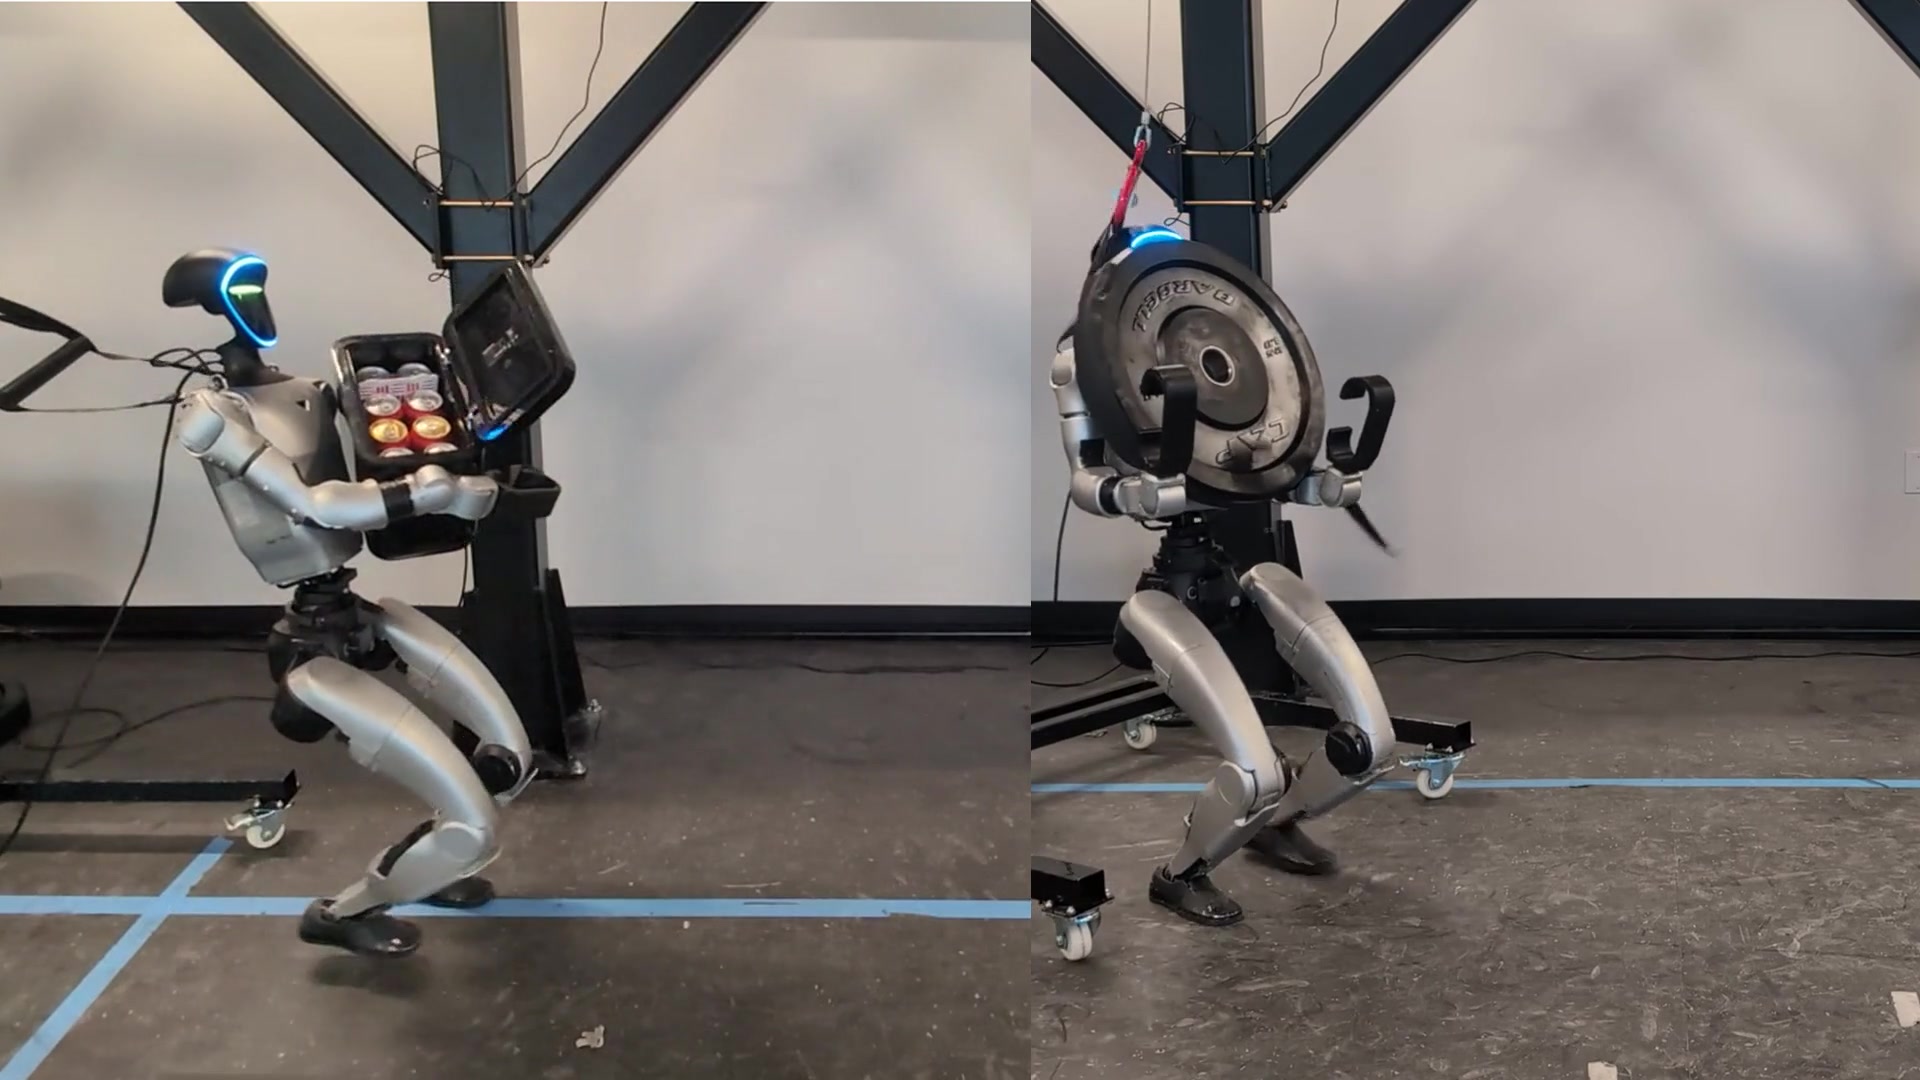
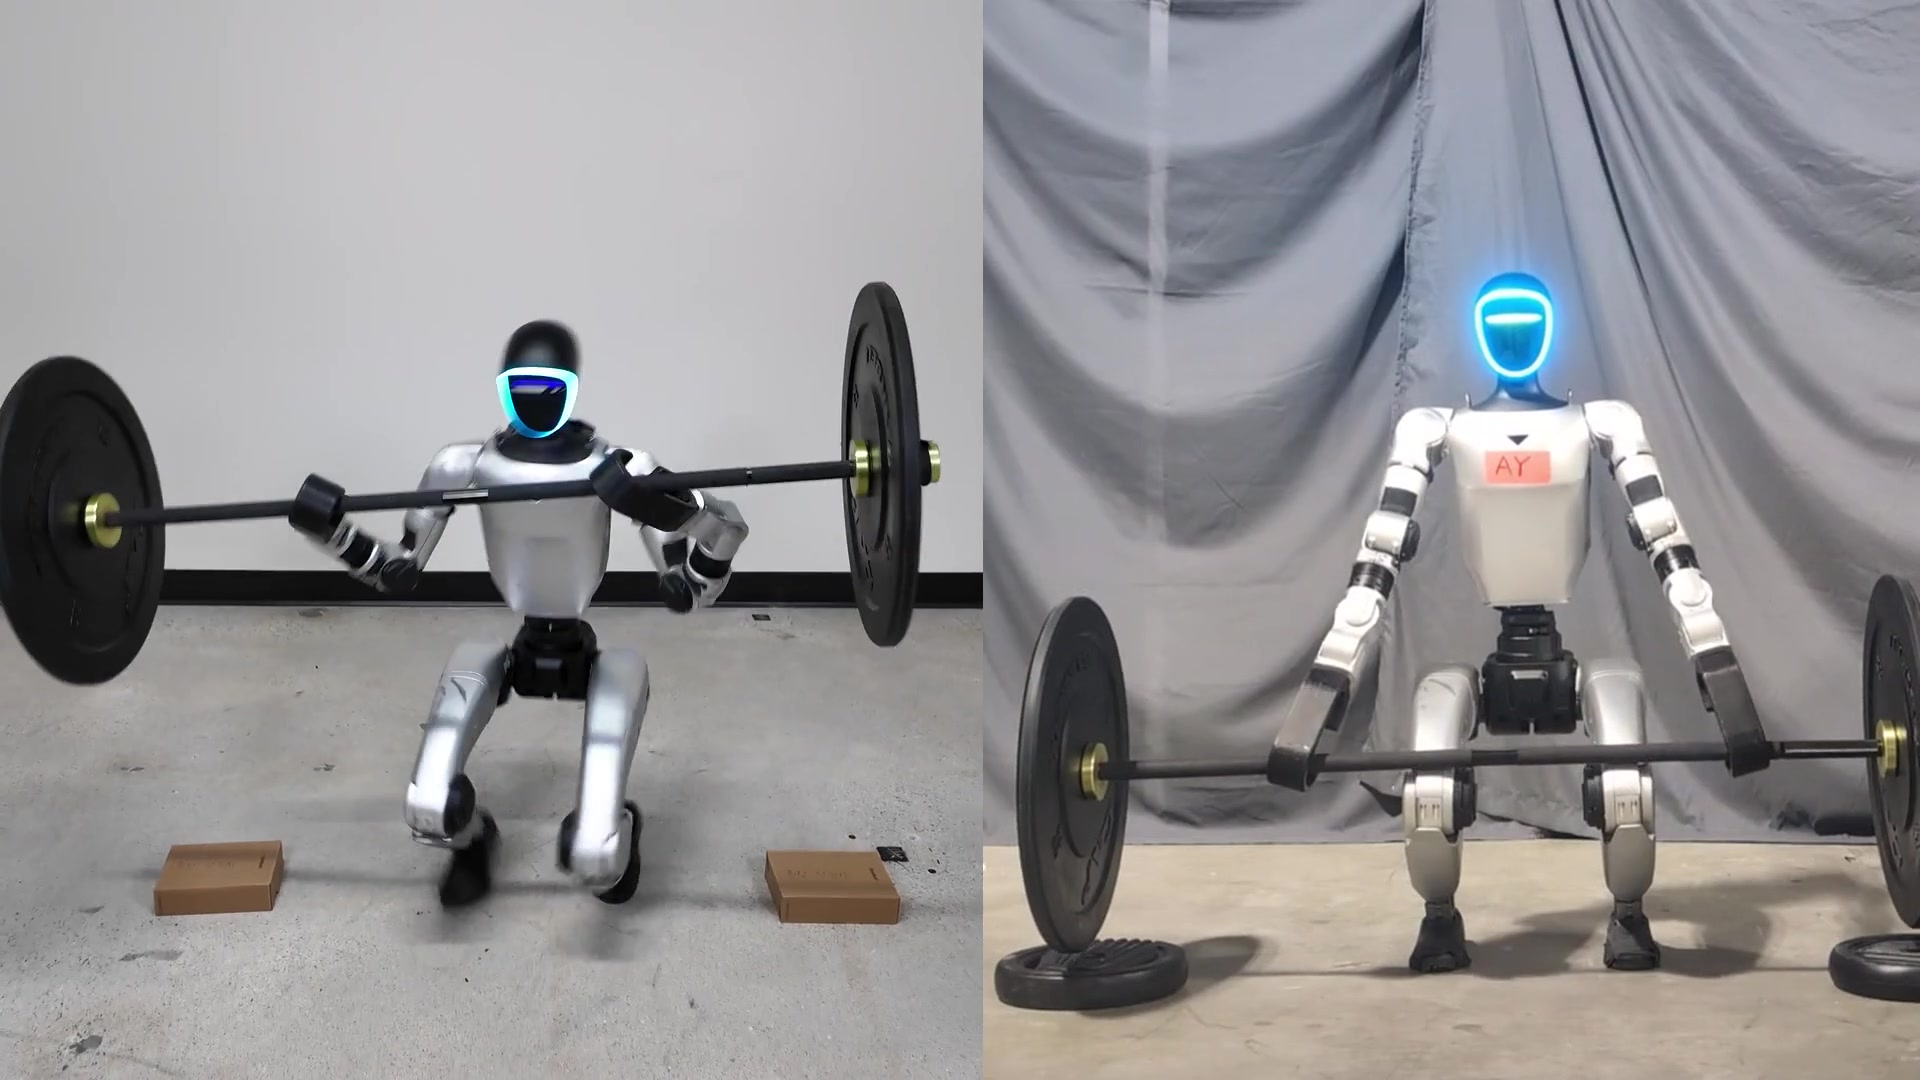
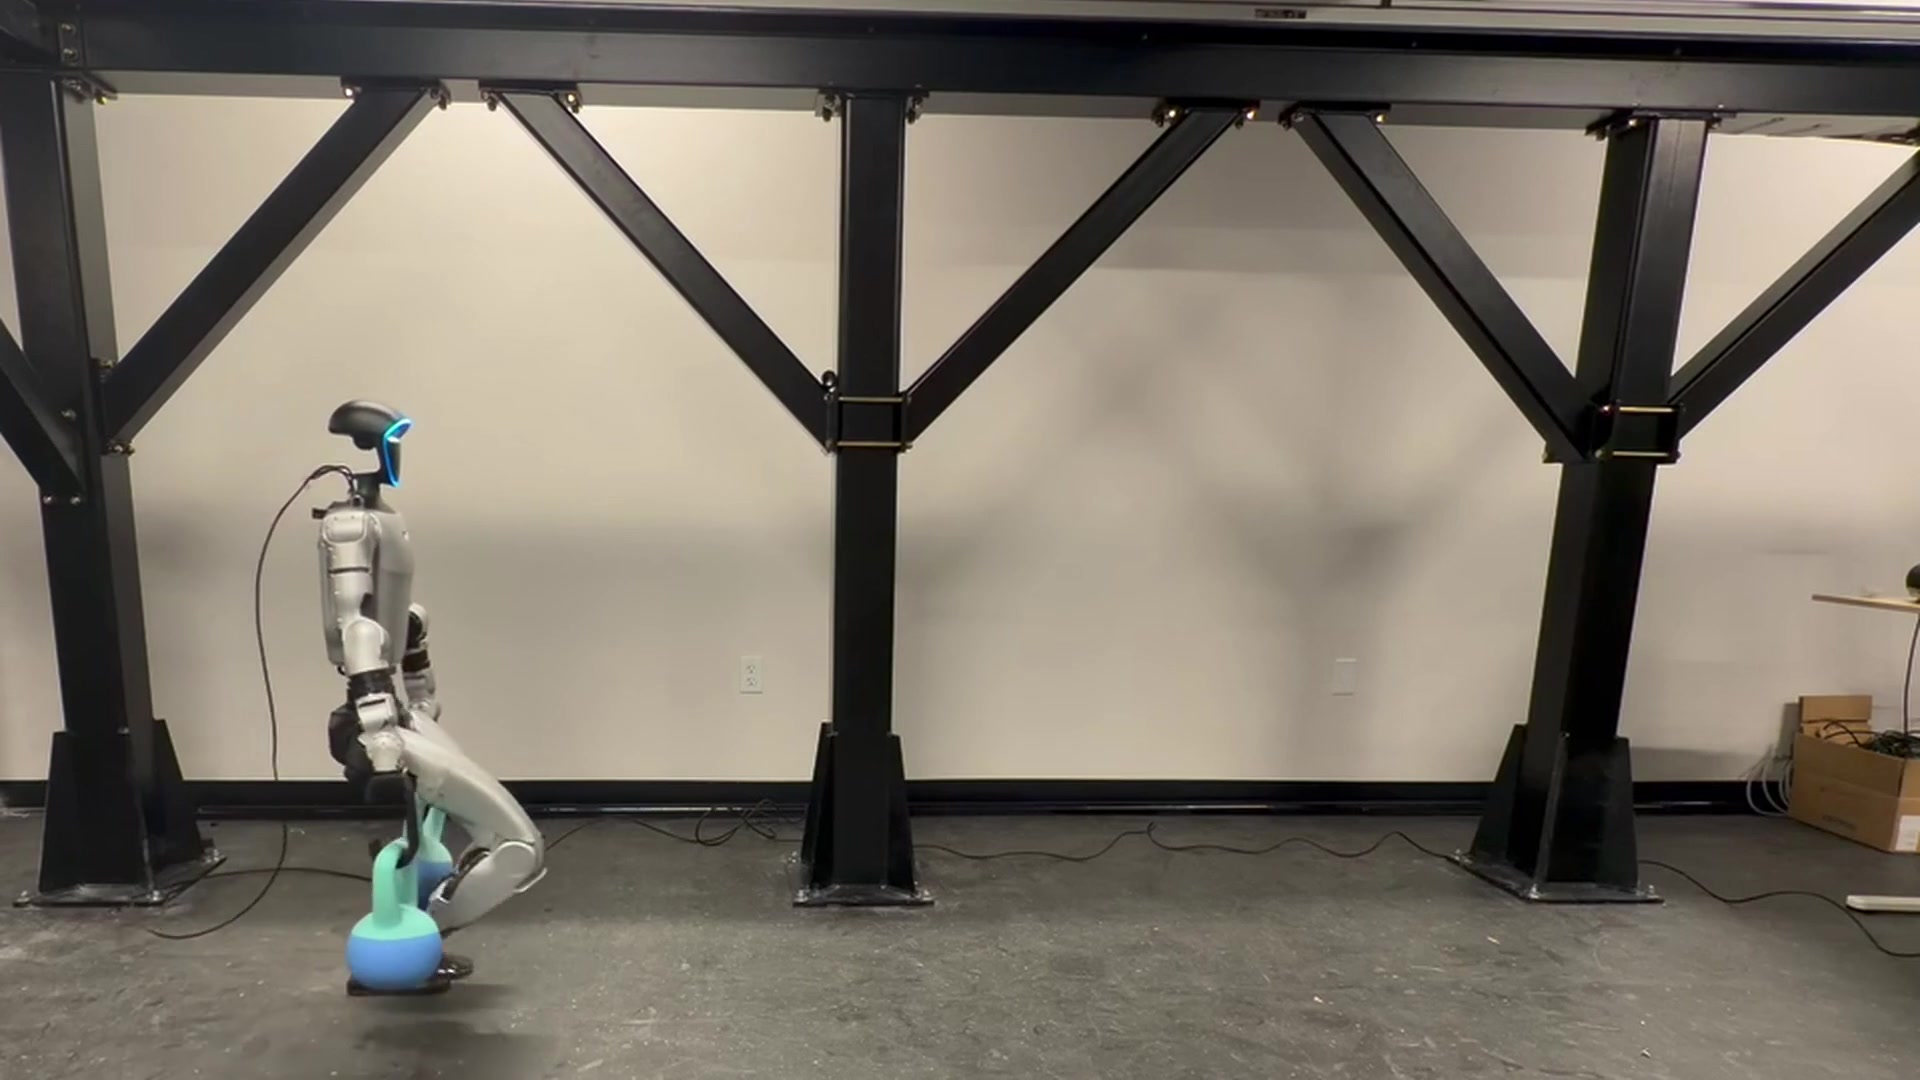
Humanoid loco-manipulation of large, heavy objects demands forceful interaction across the entire body. However, such payloads shift a humanoid's center of mass and impose sustained loads across the upper body, challenging balance and tracking. We present HULK, a whole-body control framework for forceful loco-manipulation. Using model predictive control (MPC) to guide reinforcement learning with predictions of the loaded dynamics, we train two teachers: one tracks arm motions under wrist forces, and the other locomotes while holding large objects against the body. A capture-point control barrier function augments the wrist-force teacher during training to improve balance under load. We distill both teachers into a single policy. We evaluate our method on a Unitree G1 in both simulation and the real-world. In simulation, the teacher with the barrier function achieves the lowest forward and lateral velocity tracking errors at 10 kg per arm among evaluated controllers and reduces aggregate balance metric by 35.7% relative to MPC-guided reinforcement learning alone. Our wrist-force teacher withstands torso push disturbances of up to 130 N.
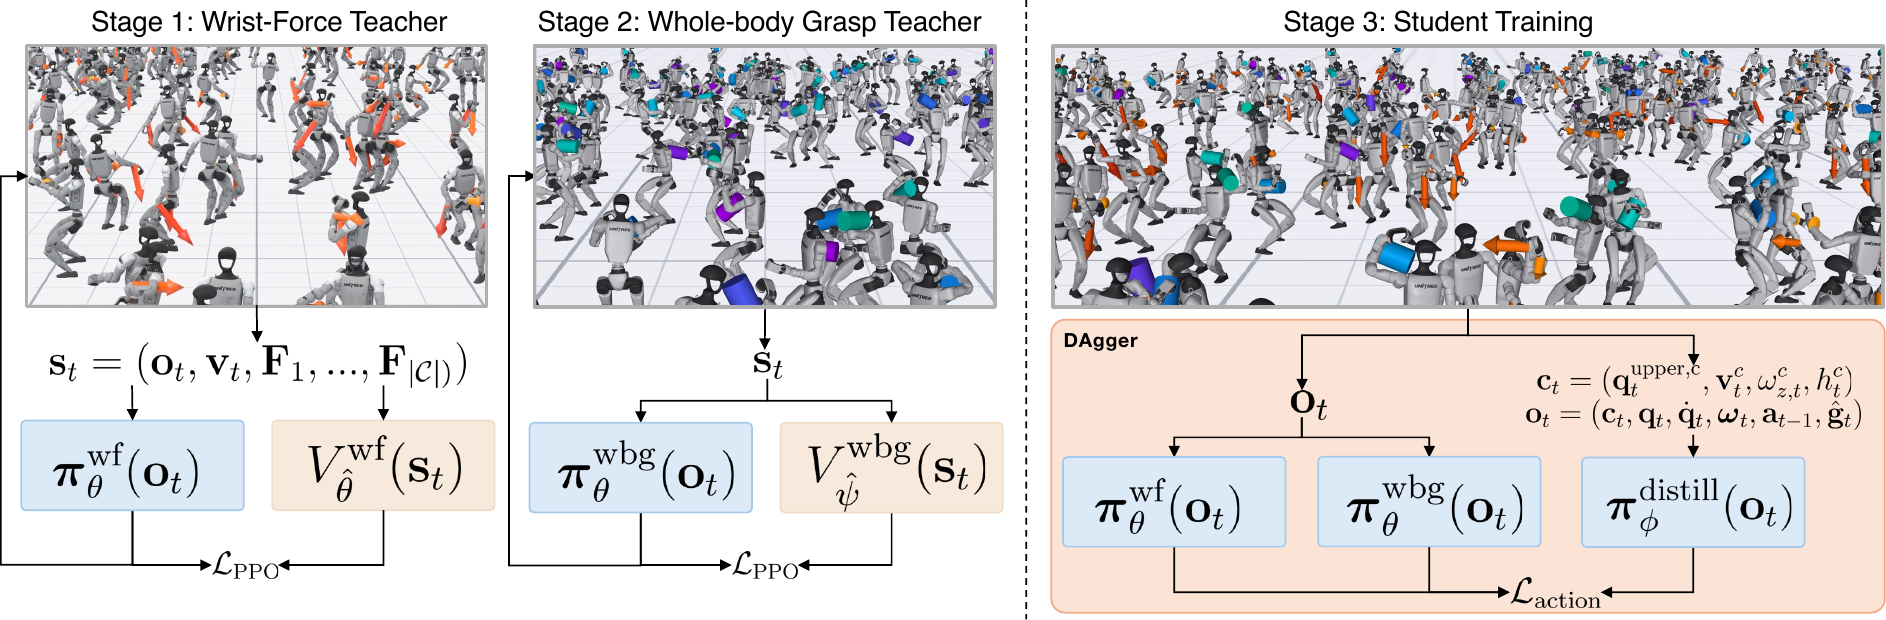
Two specialists. One WBC policy.
We train a wrist-force specialist and a whole-body-grasp specialist with MPC reward guidance, then distill them into one whole-body control policy. Capture-point constraints help the wrist-force specialist learn to balance under load.
Training A
The wrist-force specialist learns to track arm targets and motion commands under sustained wrist loads.
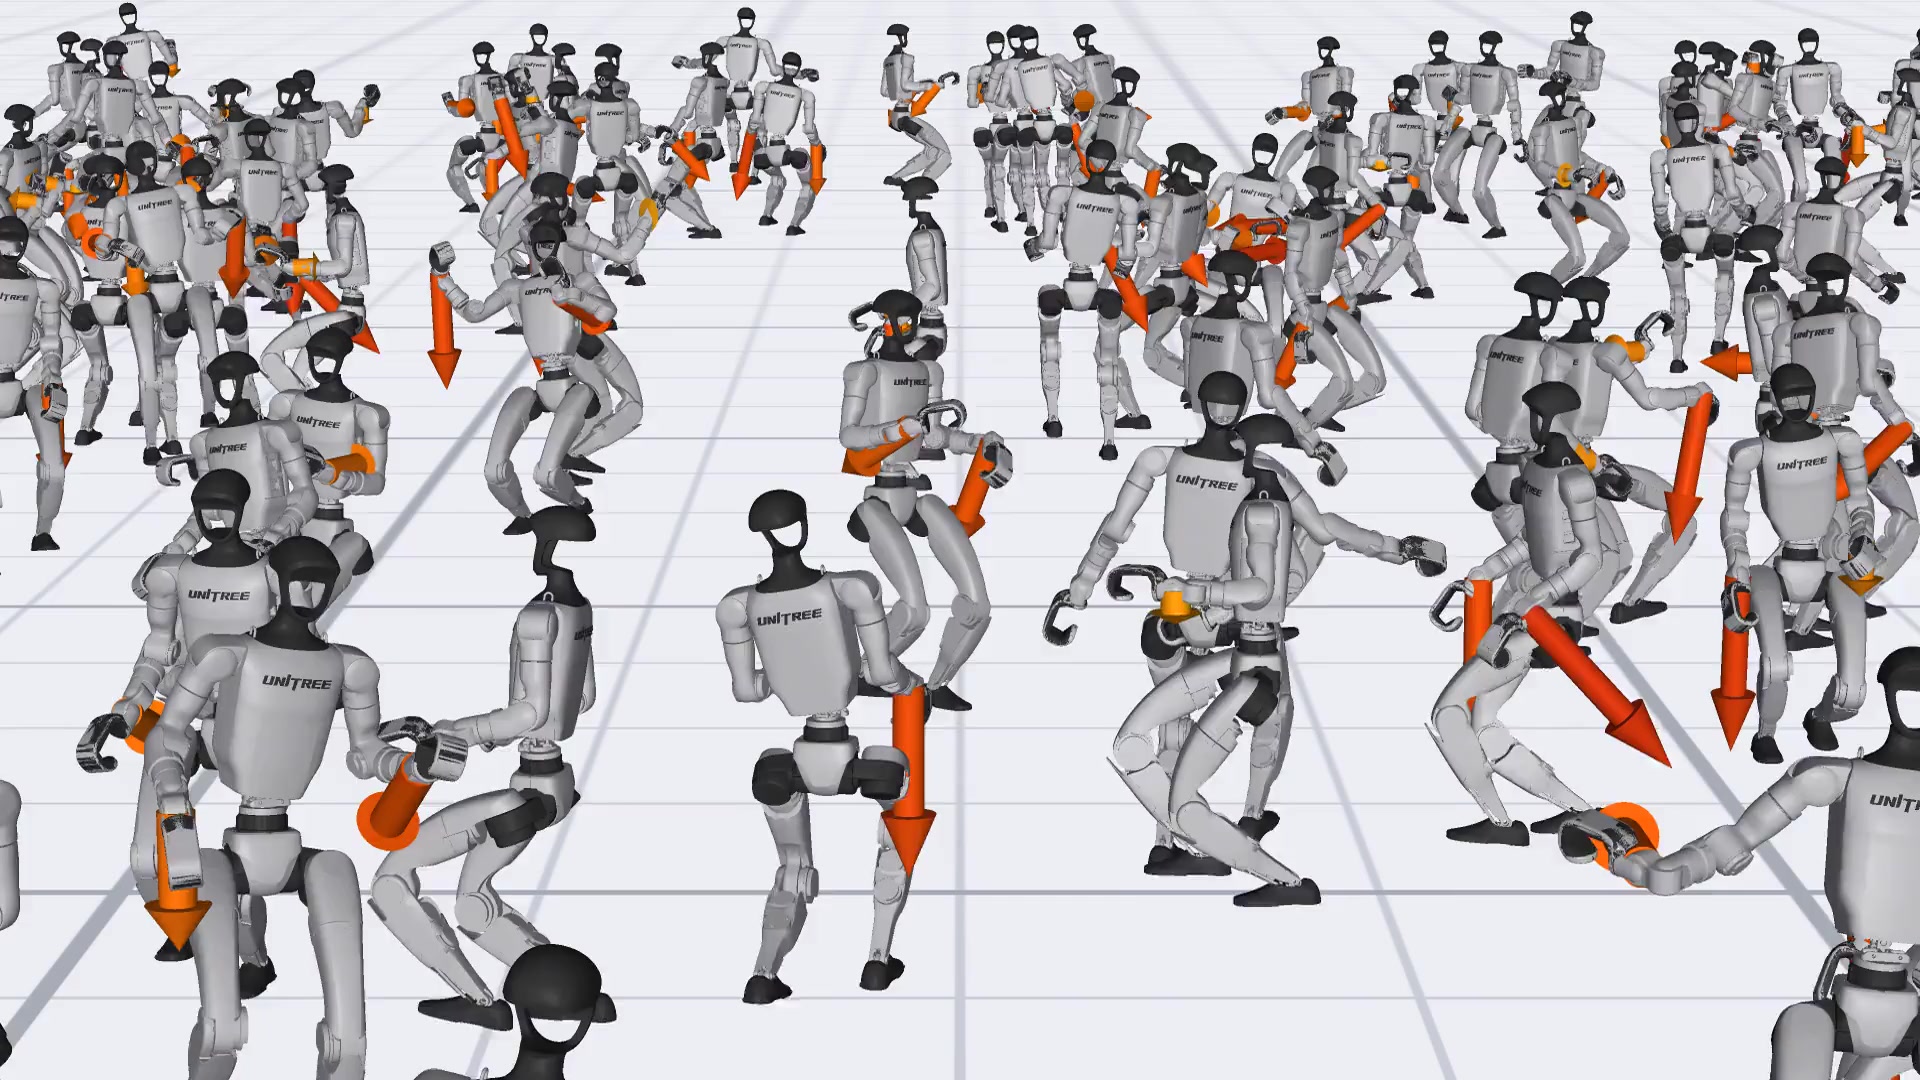
Sample a pose. Learn under force.
Training B
The whole-body-grasp specialist learns to walk while carrying objects from established grasps.
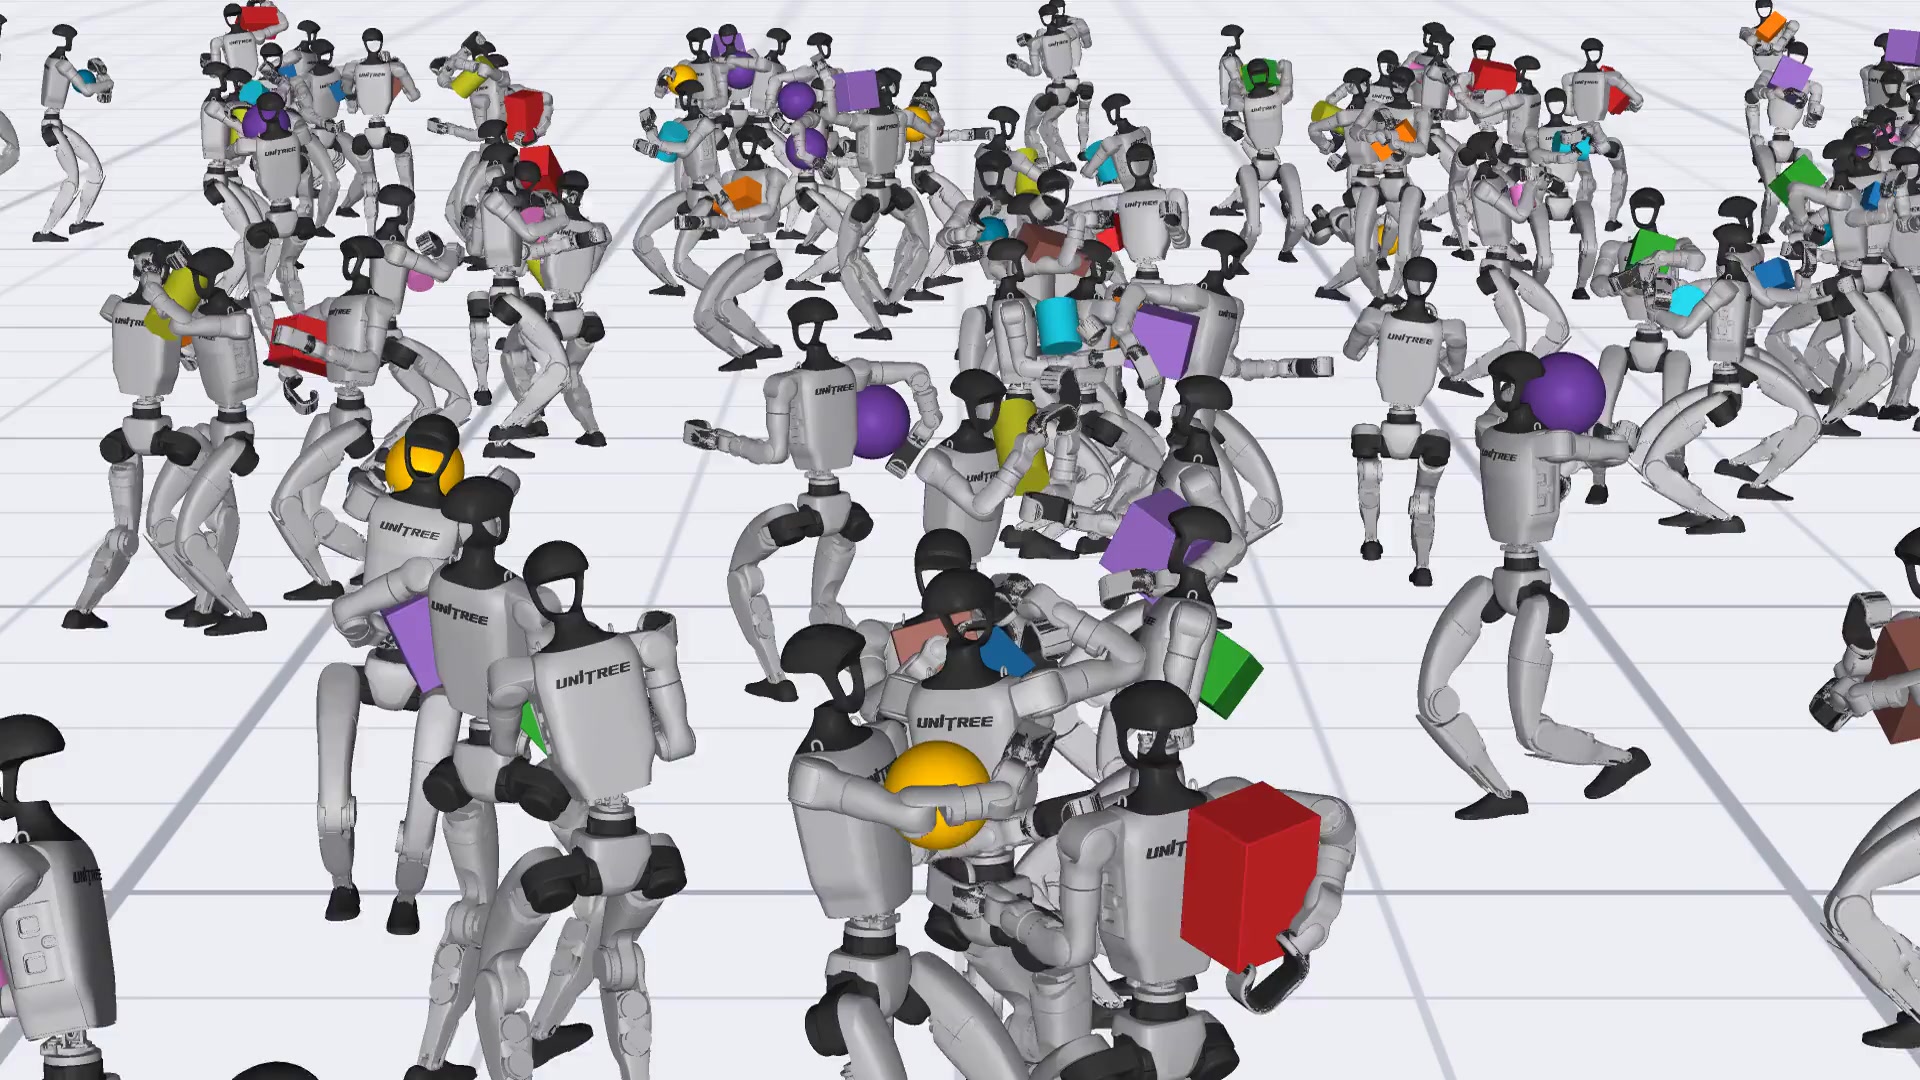
Initialize a grasp. Learn to carry.
Key Findings
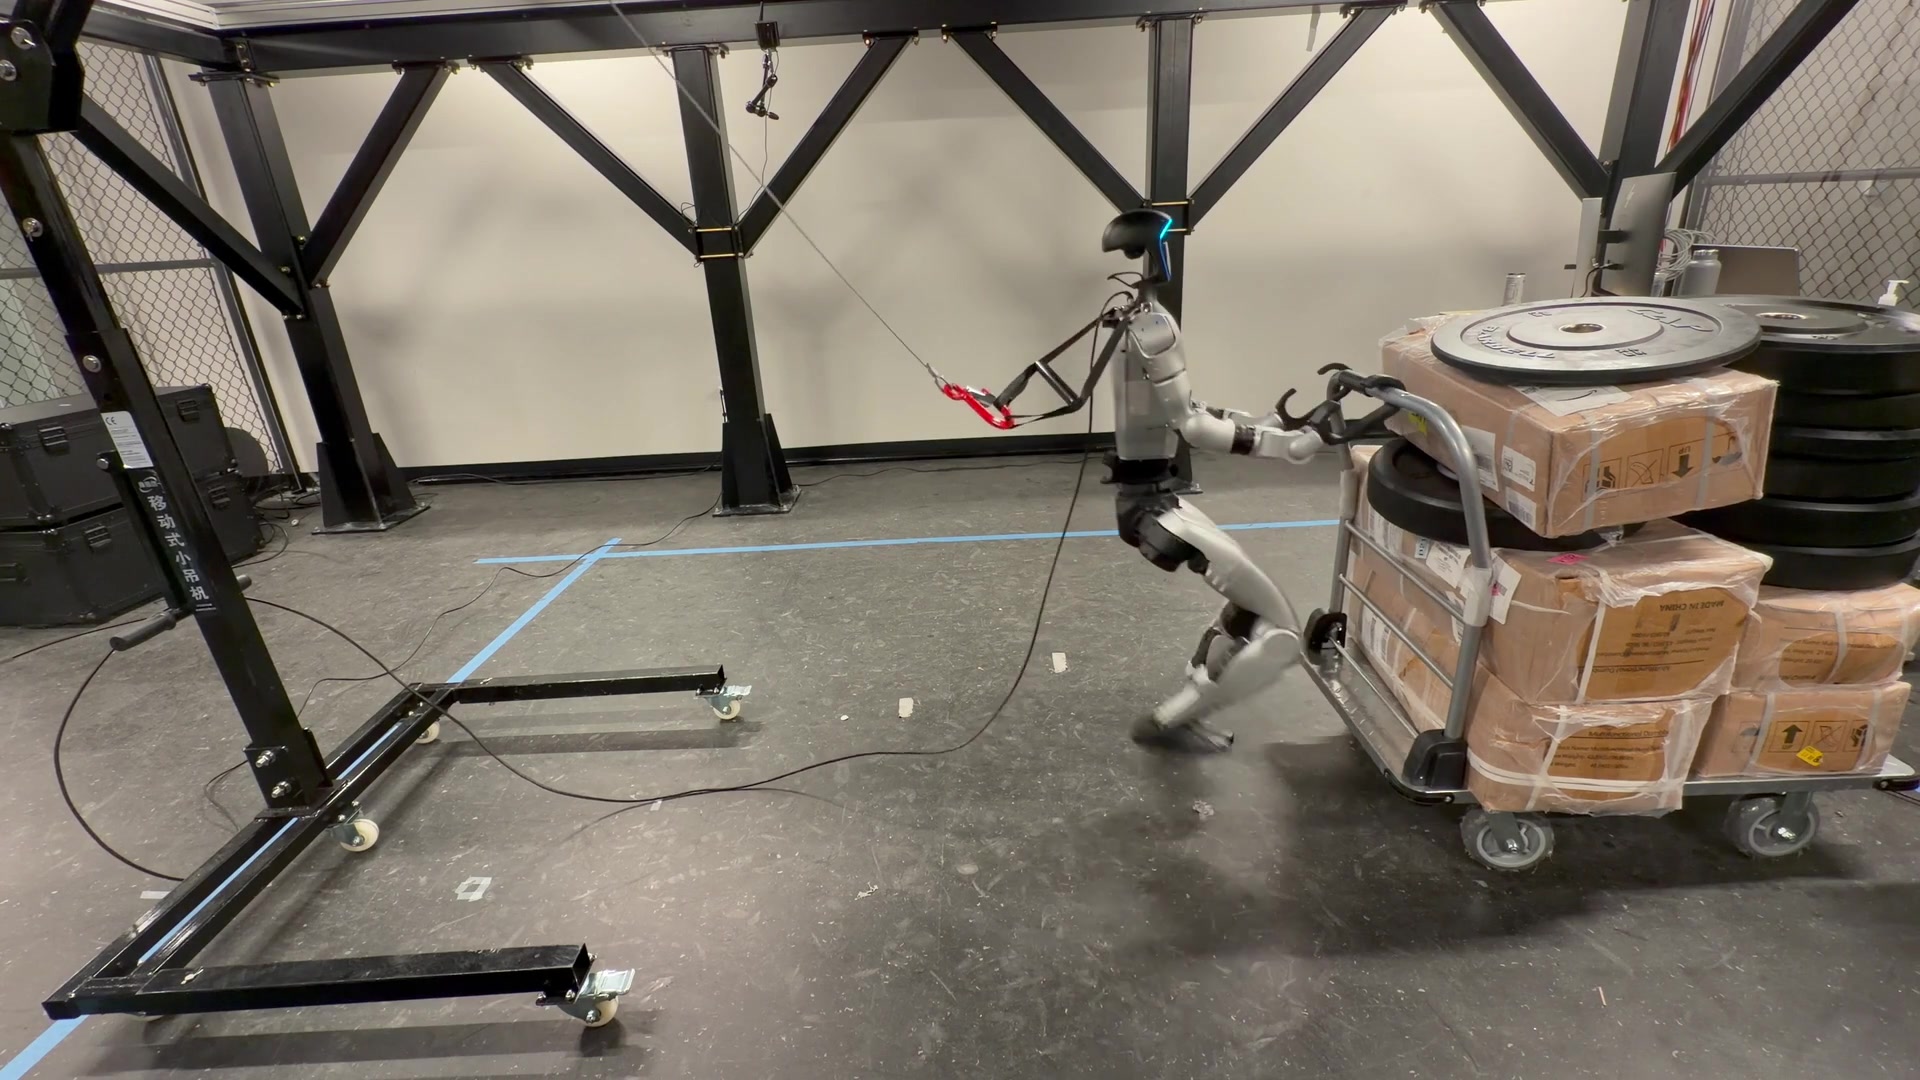
- MPC reward guidance lets the whole-body controller push and pull heavy objects, including a 300 kg cart.
- Capture-Point Constraints improve robustness to force disturbances and balance recovery, measured by DCM excursion.
Forceful cart pulling
The whole-body controller pulls a cart loaded to 300 kg on real hardware.
Better velocity performance
Lower tracking error while carrying 10 kg per arm in simulation.
Better balance recovery
DCM excursion after one-second torso pushes across the 50–100 N sweep in simulation.
Velocity and recovery metrics compare teachers trained with and without capture-point constraints across five simulation evaluation seeds. The 300 kg cart pull is a separate hardware demonstration. Protocol and full results ↗
MPC Reward Guidance
Two specialists learn with model predictive control (MPC) guidance. Their walking rollouts show planned footsteps and predicted body motion under changing loads.
Grasp MPC
Fridge carrying under a 0.5 m/s command as payload varies from 0.5 to 2 kg. Footstep targets and predicted body motion are shown at real-time playback speed.
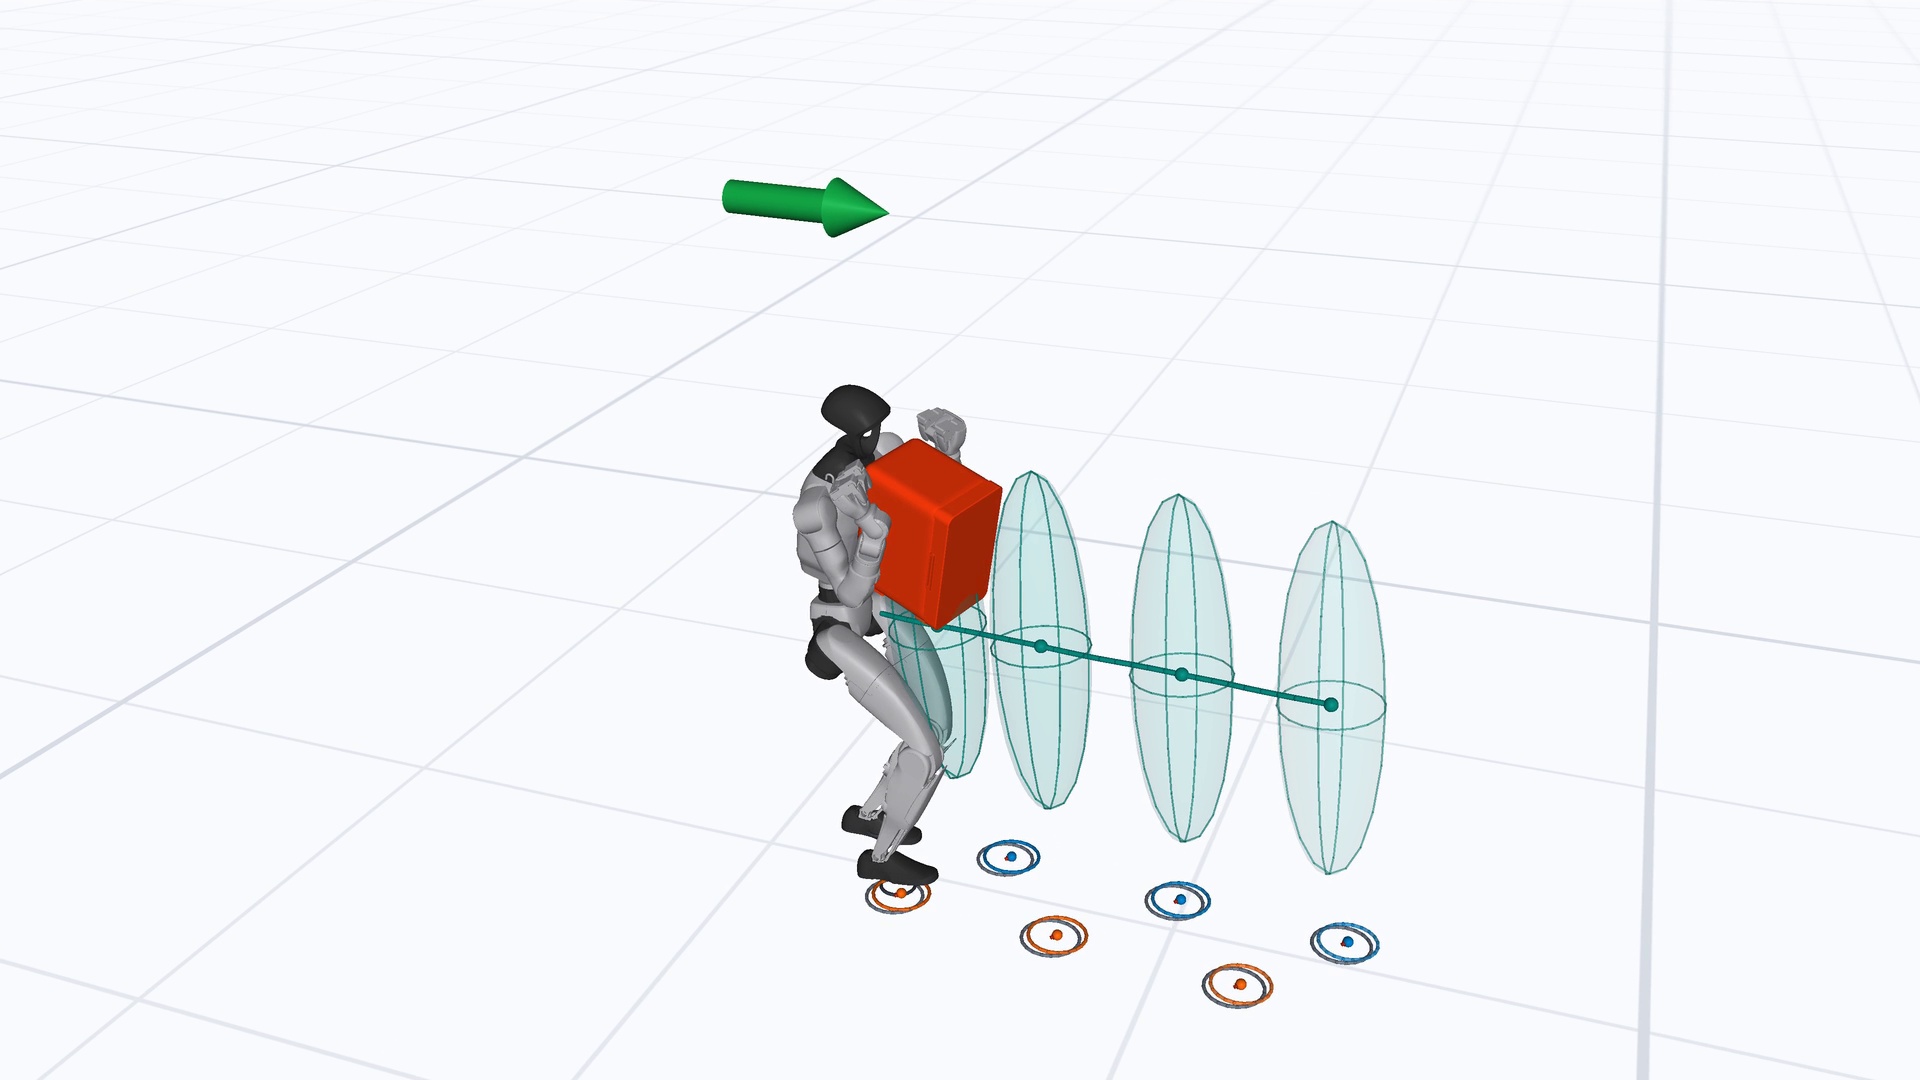
Carry through changing loads.
Wrist-Force MPC
Walking under a 0.3 m/s command with a 40 N total backward load for five seconds, followed by release. Footstep targets and predicted body motion are shown at real-time playback speed.
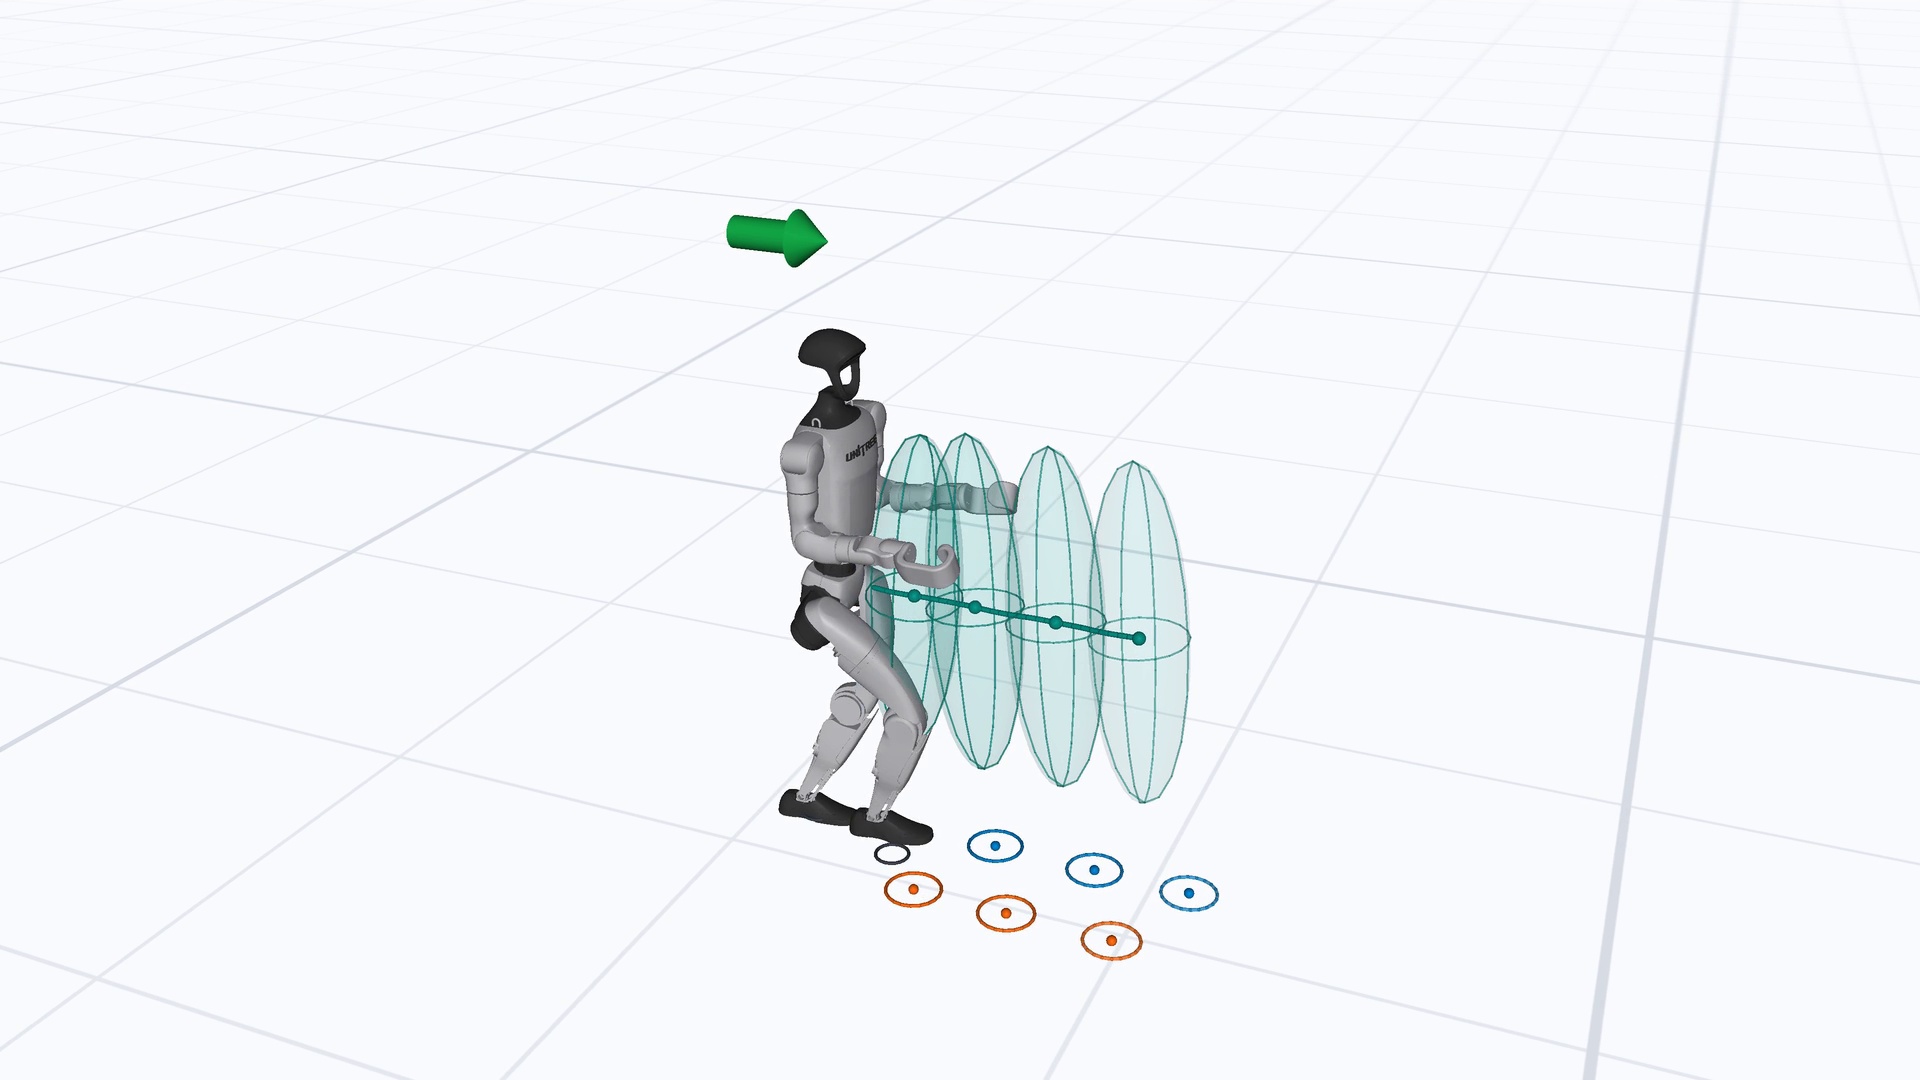
Walk under an applied force.
Simulation demonstrations with different loads. The displayed 2.1-second preview extends the native 0.7-second MPC horizon.
MPC optimization for forces
One frozen pose per clip; arrows show 128 solver iterations, not robot motion.
Joint grasp and ground forces
Torso/arm grasp forces and foot ground-reaction forces update together in one experimental solve.
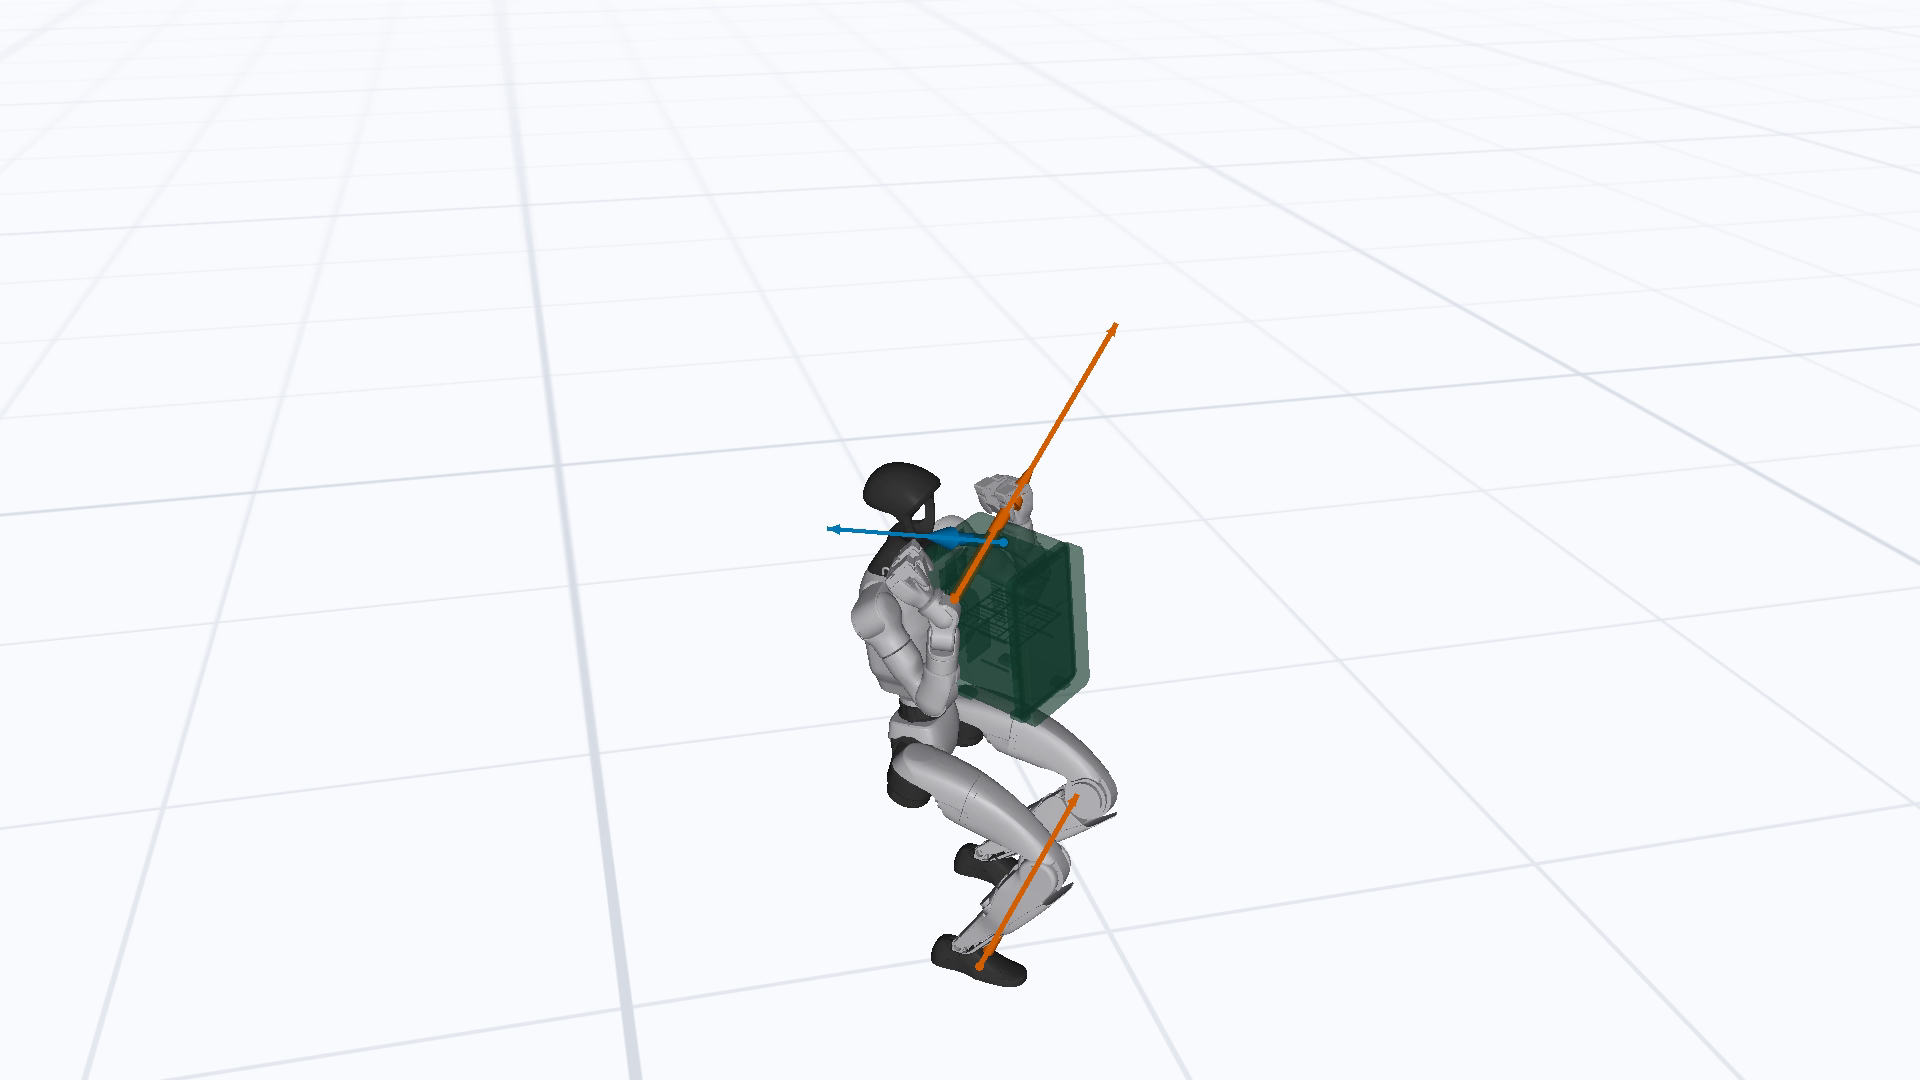
Grasp and foot forces optimize together.
Locomotion forces
Foot and applied-load force decisions update through one locomotion solve.
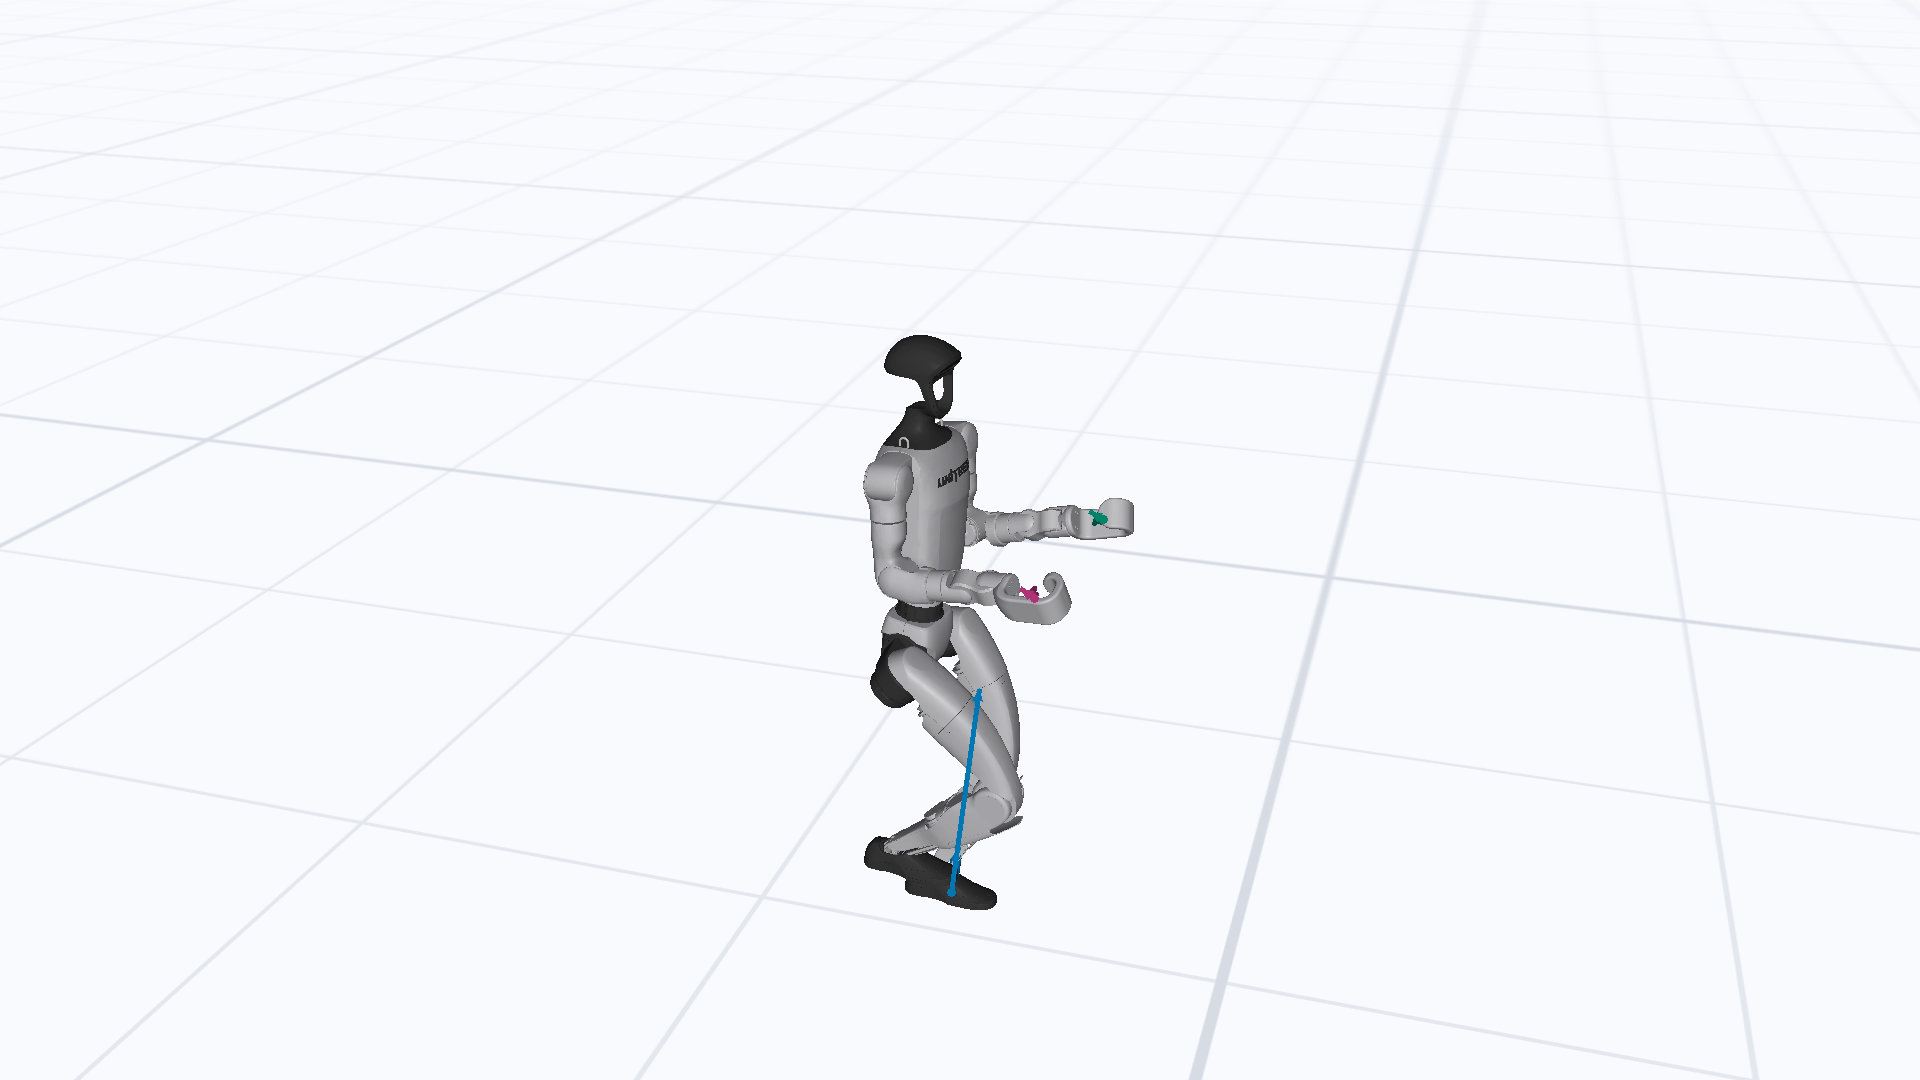
Force arrows change; the robot stays still.
CBF-RL
Capture-point barrier guidance teaches the force teacher to recover balance during training.
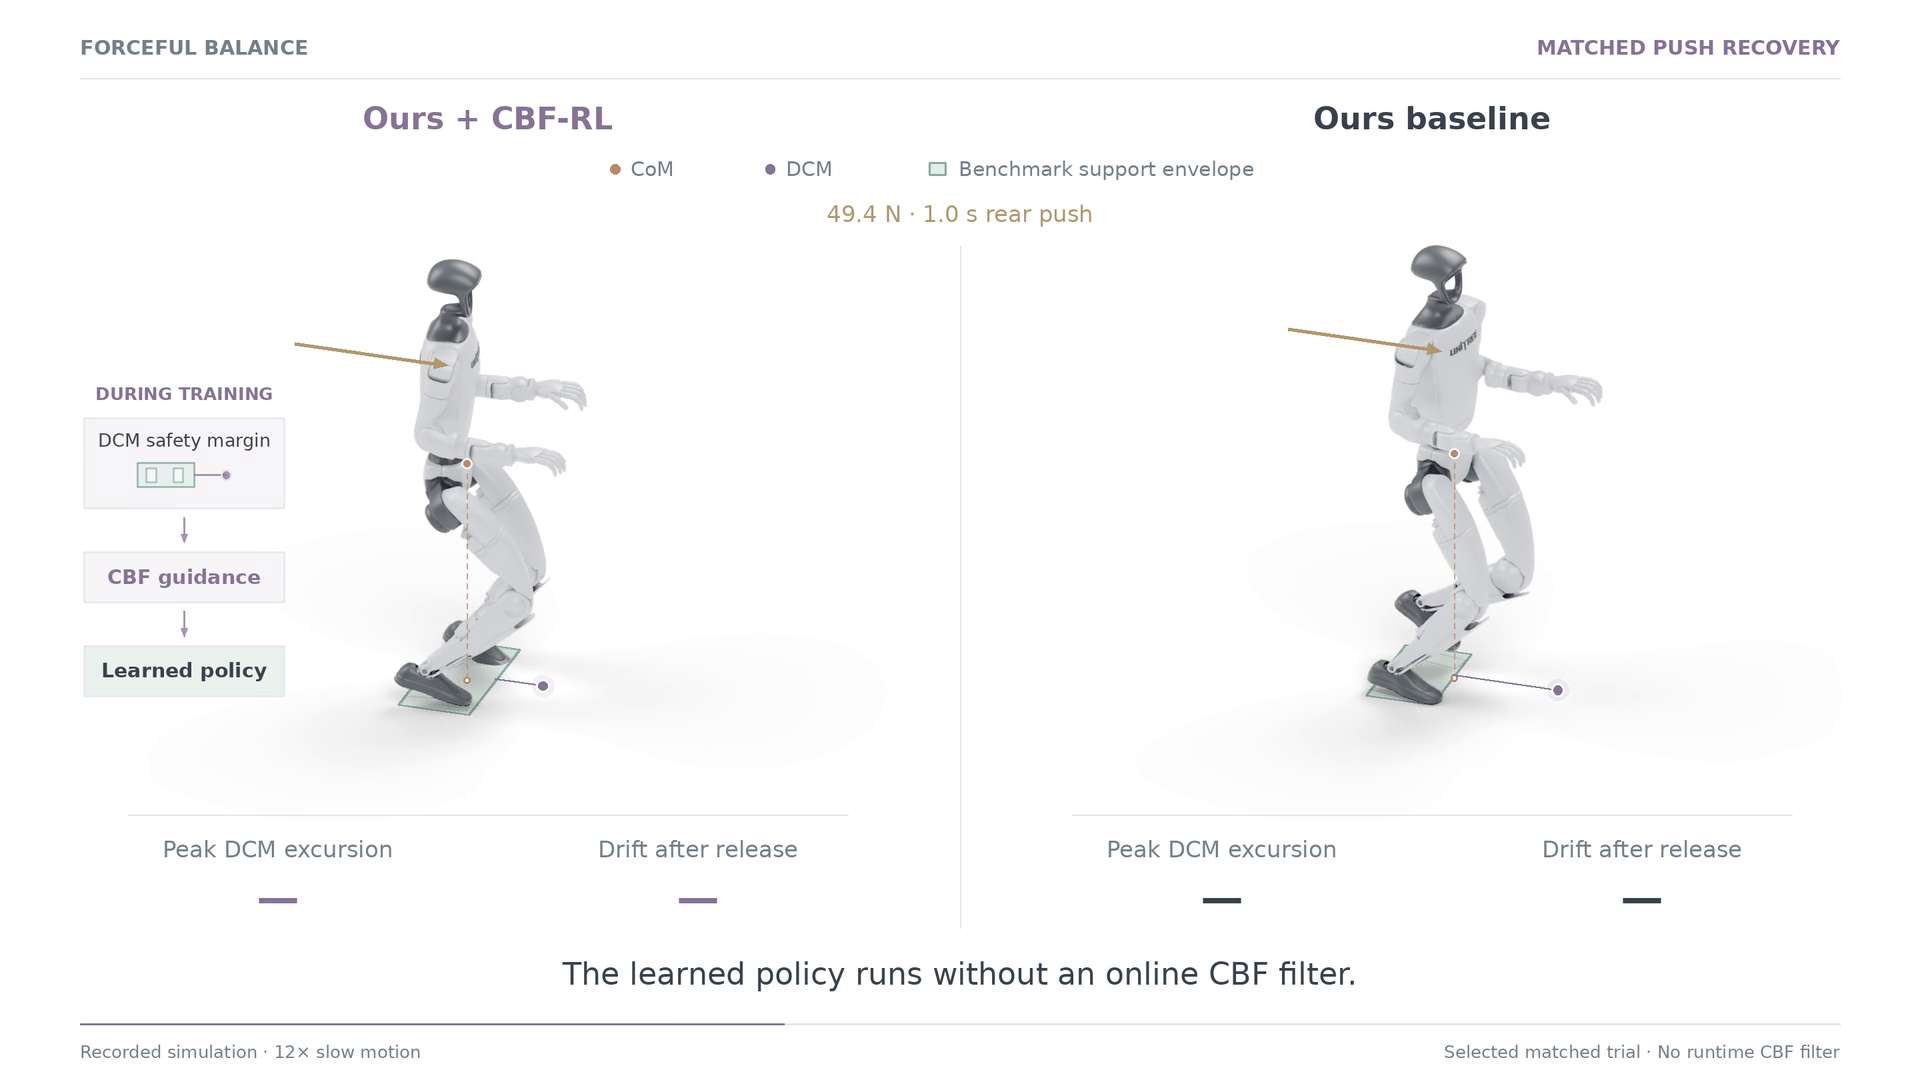
Capture point, support regions, recovery.
Simulation: Push Disturbance Recovery
FALCON, AMO, Thor, HULK, and HULK + DCM-CBF receive the same 107.3 N push for one second.
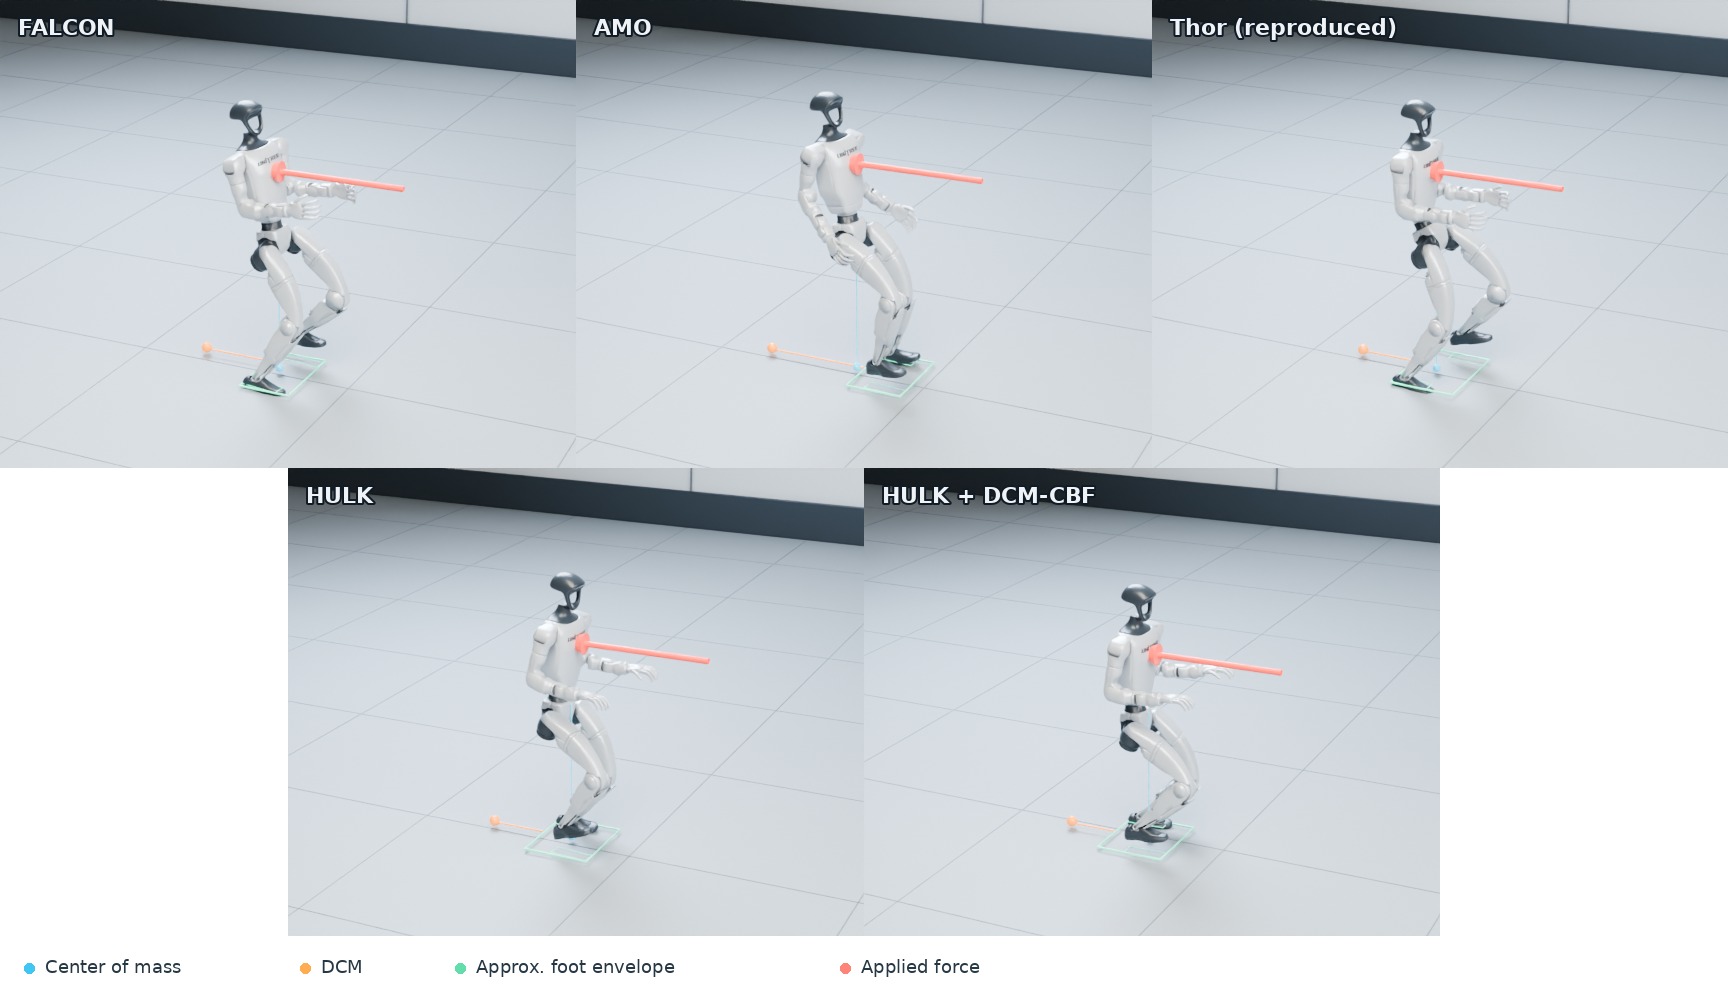
Push disturbance recovery
Blender replay of a new matched trial (seed 0), shown at 1× speed. Early-ended trials hold their final recorded state.
Real World Results
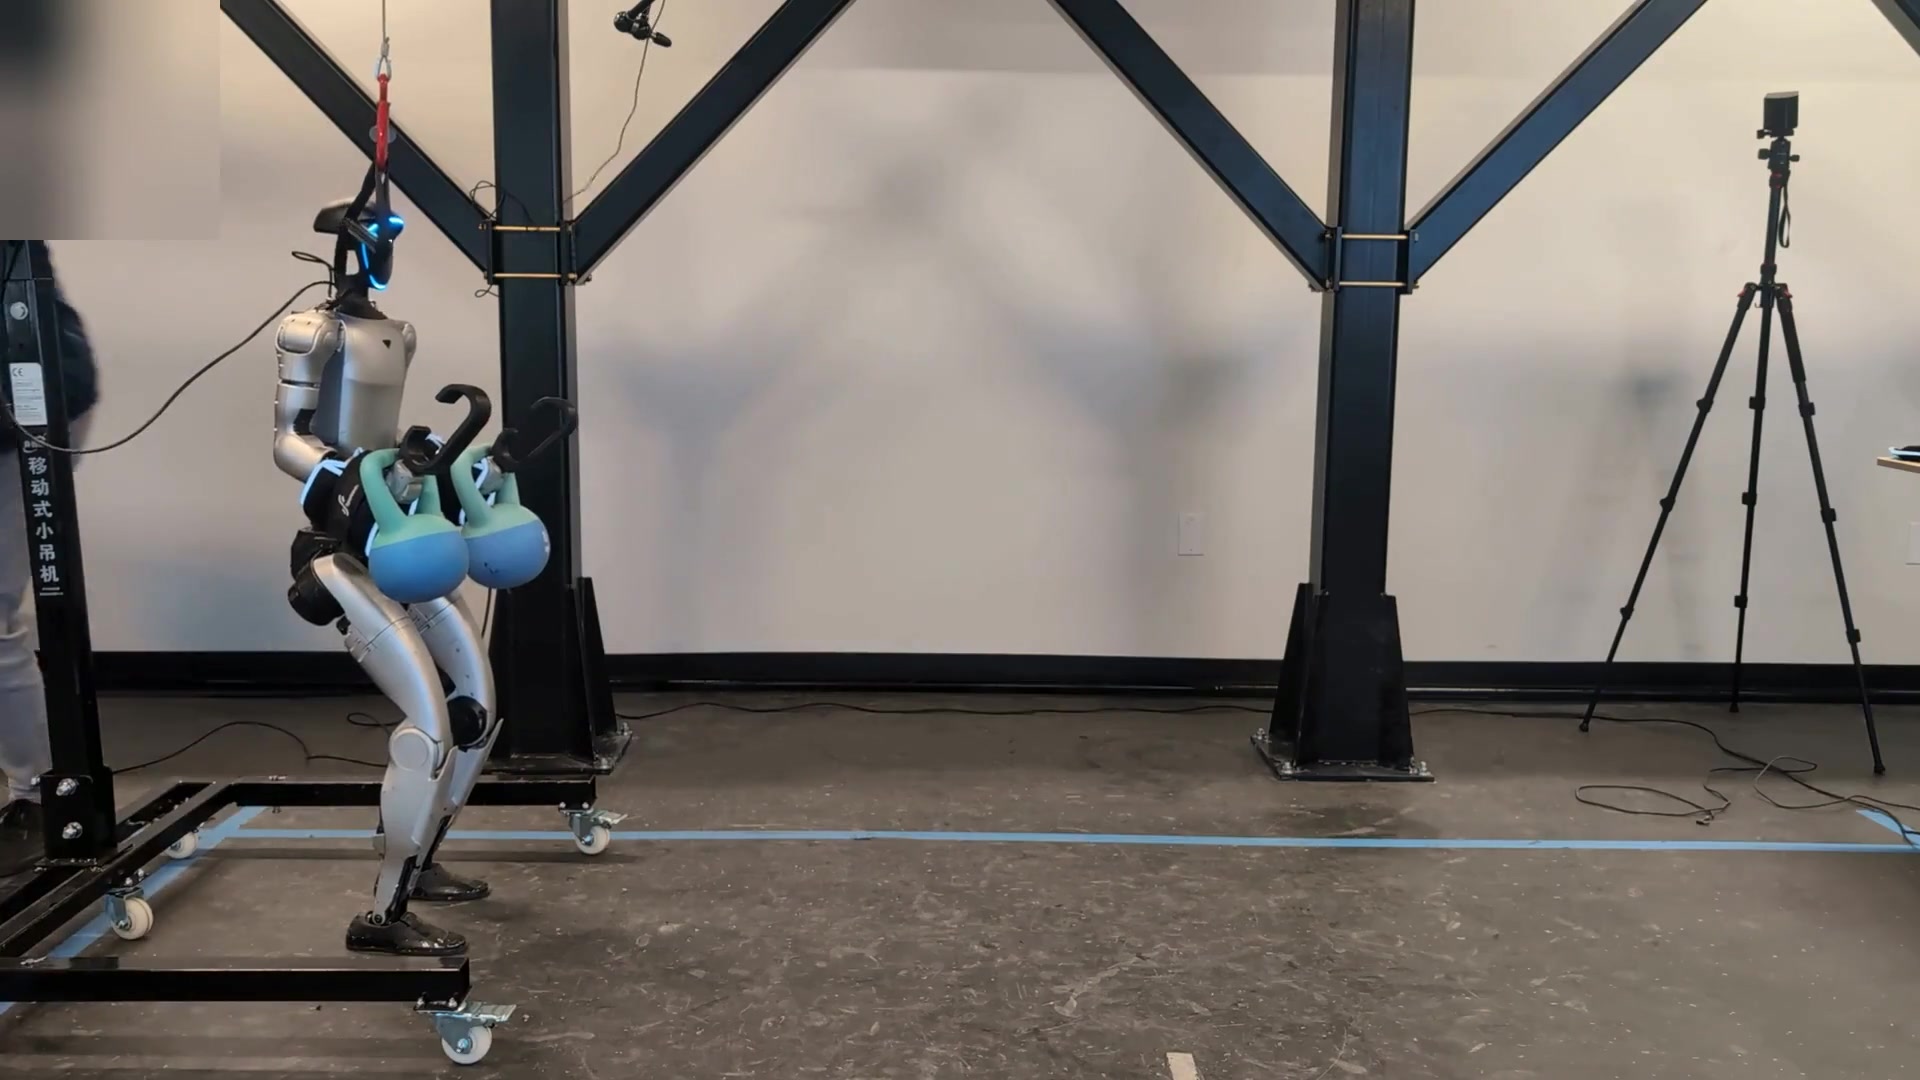
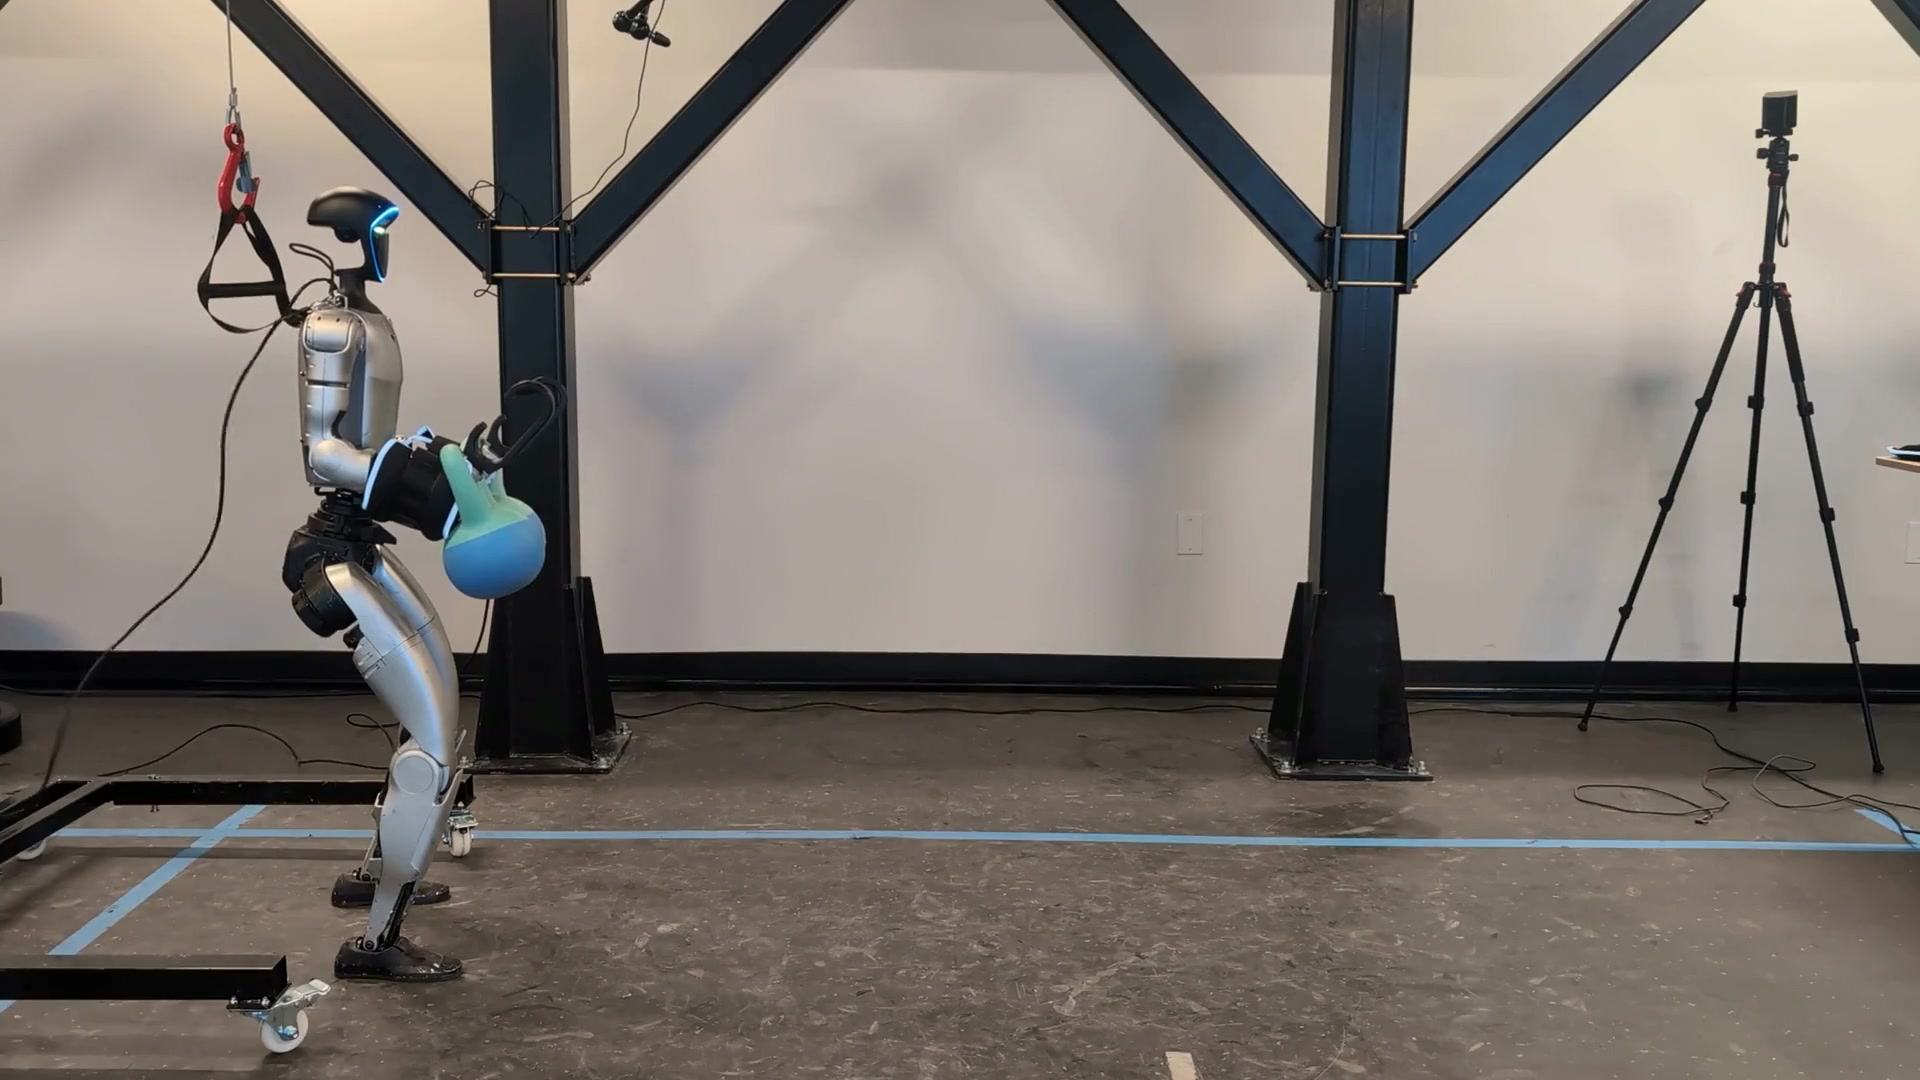
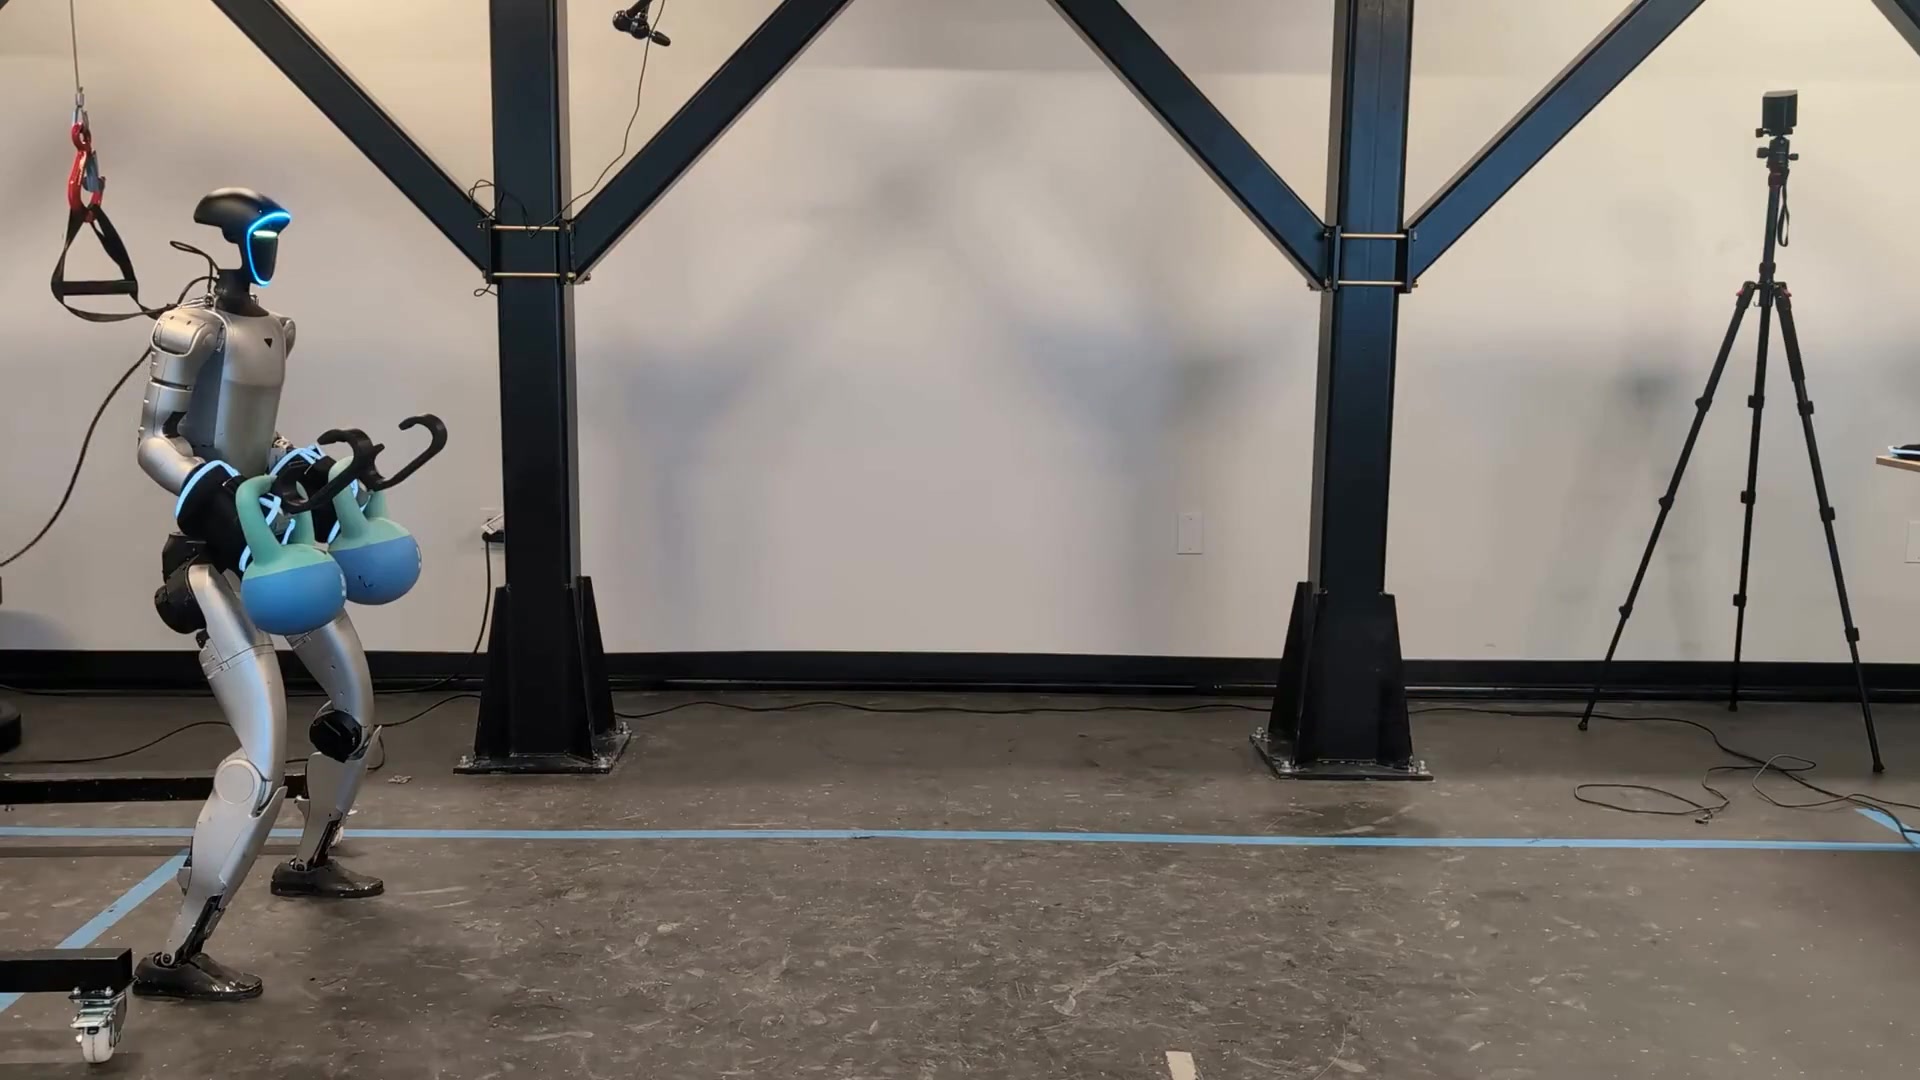
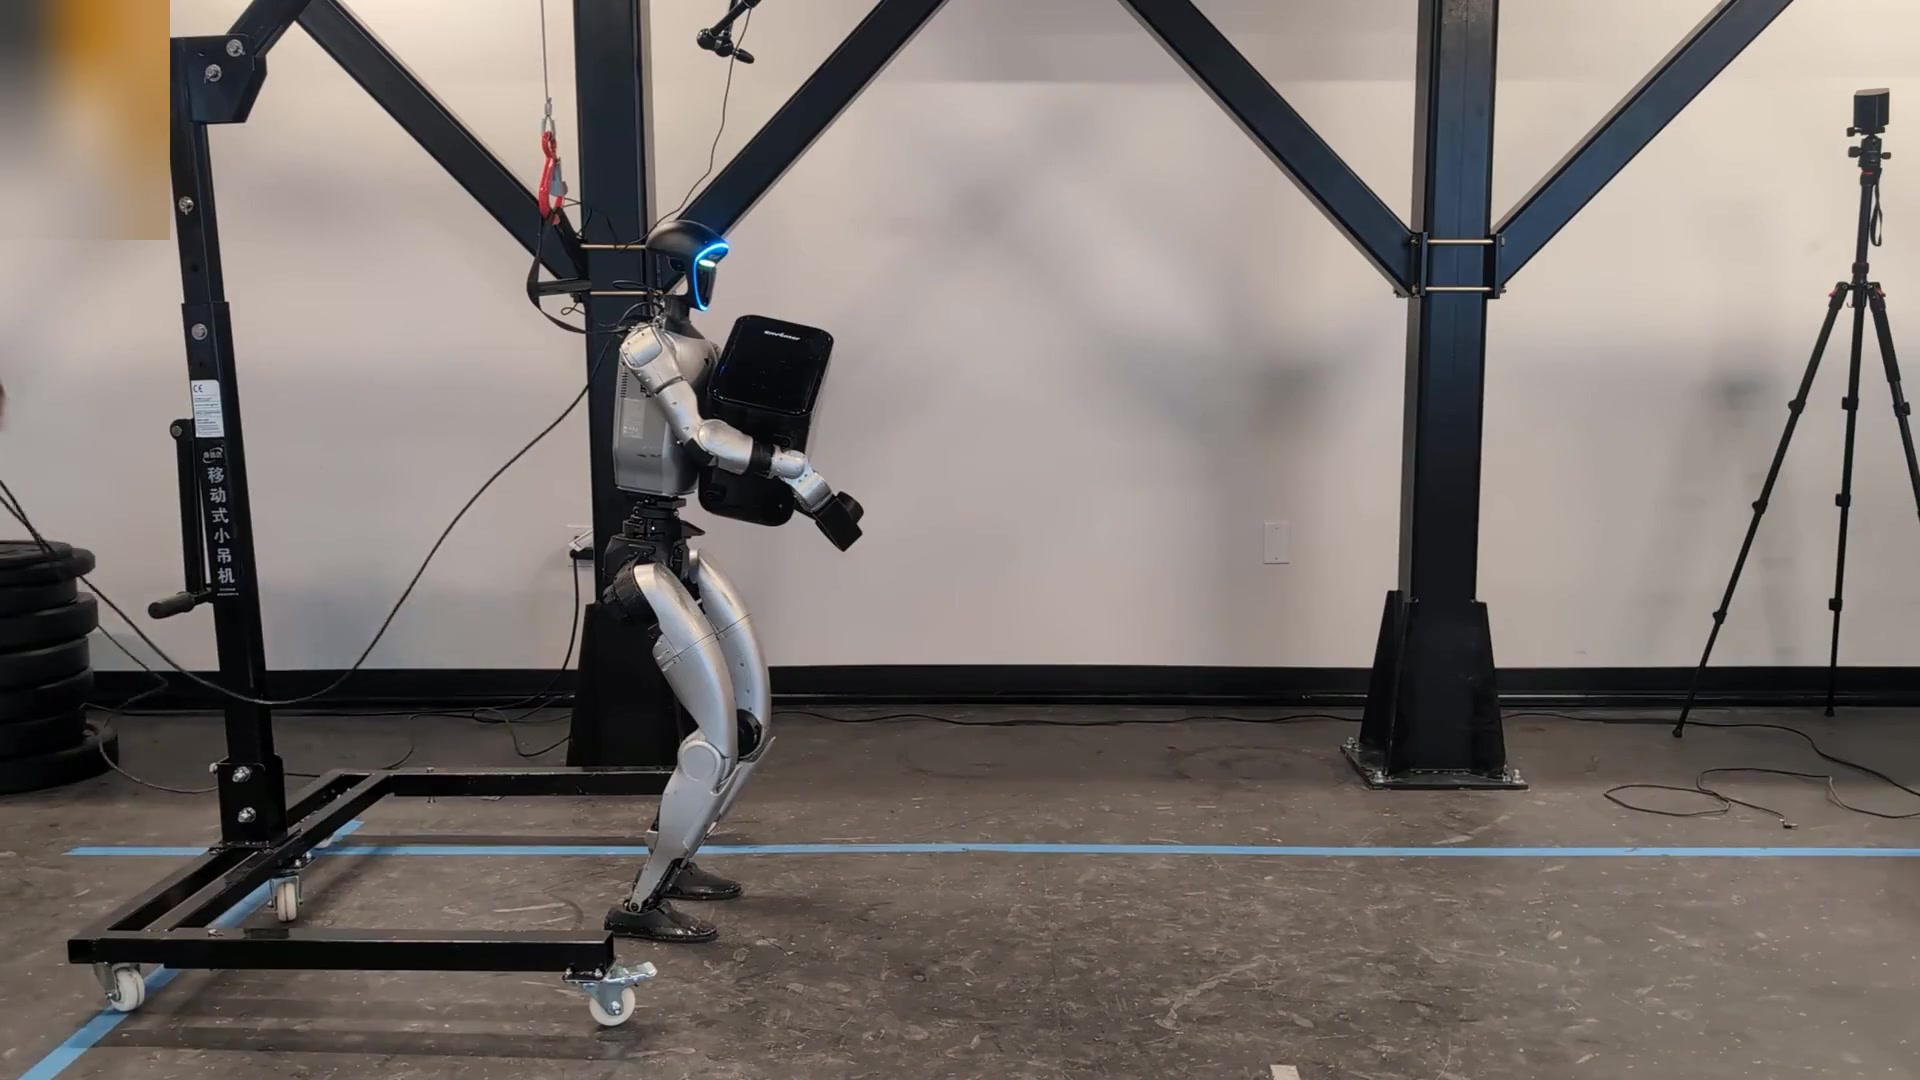
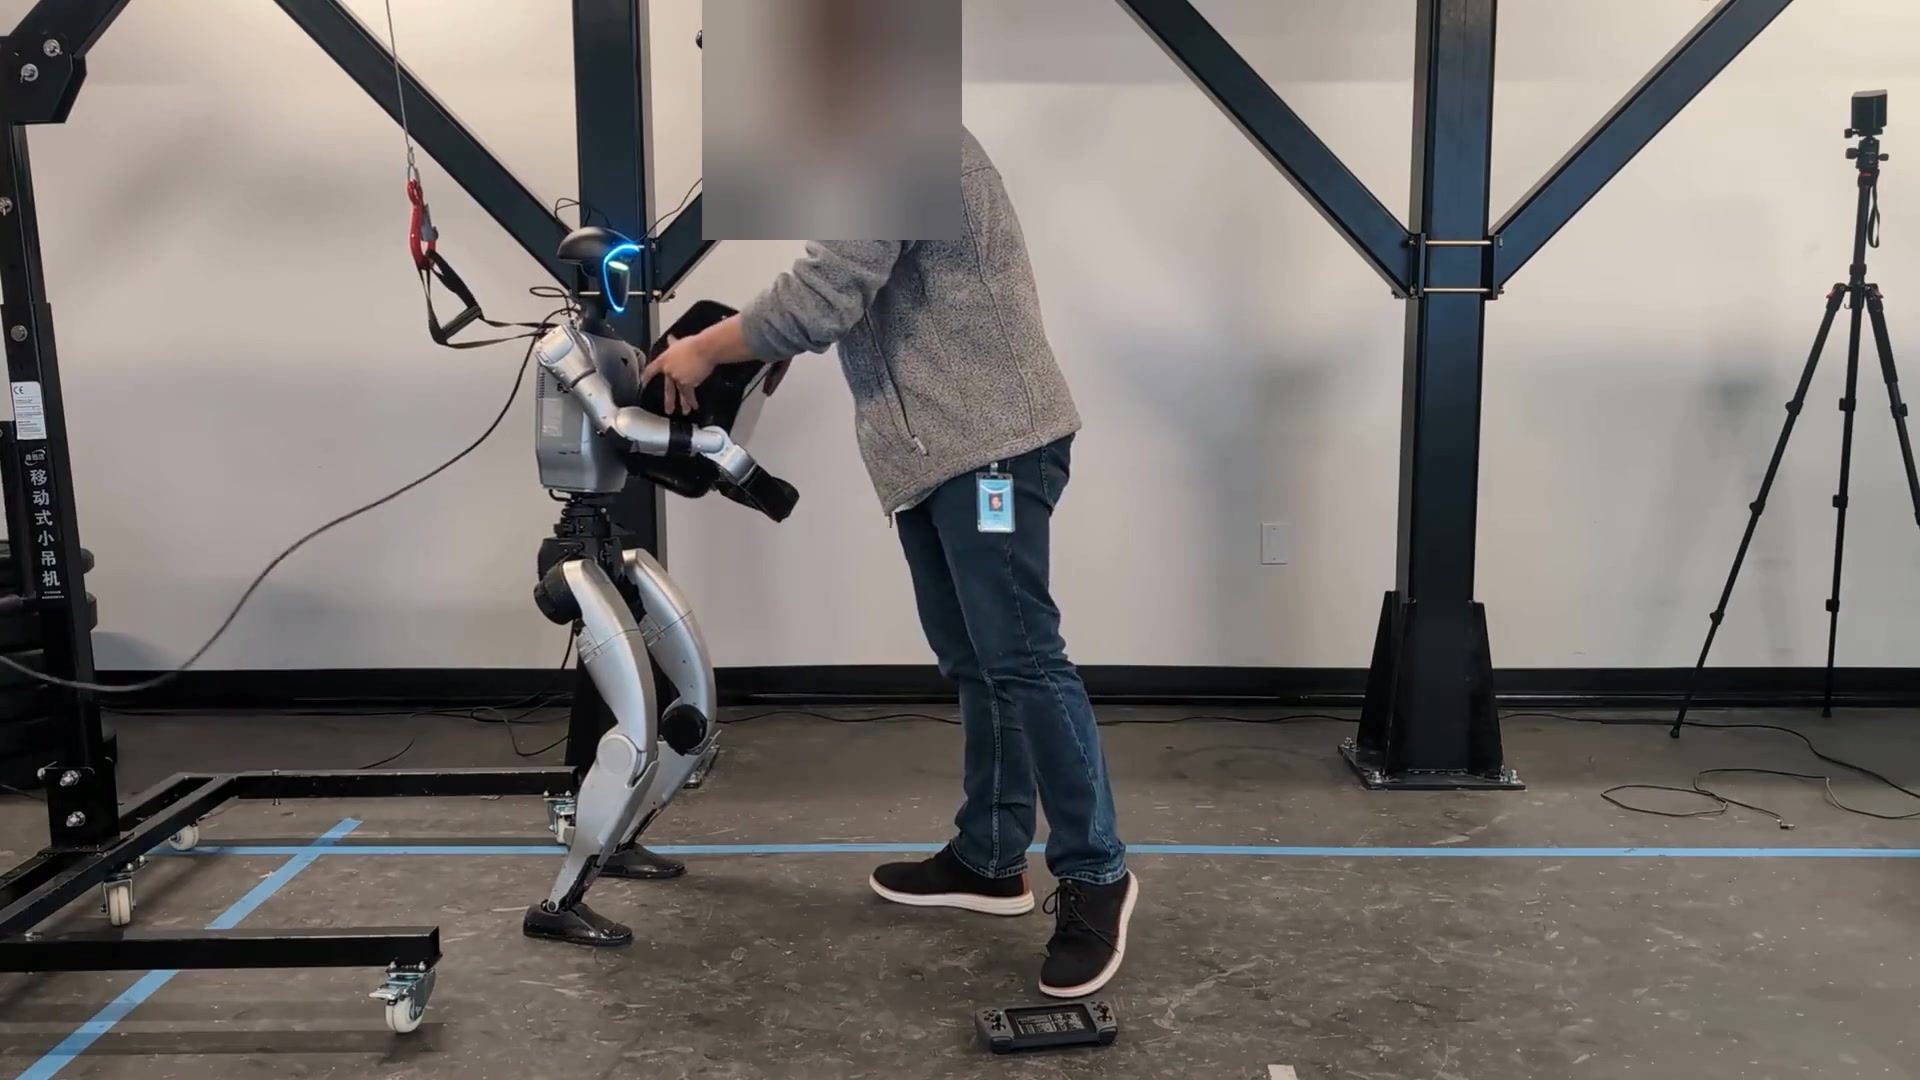
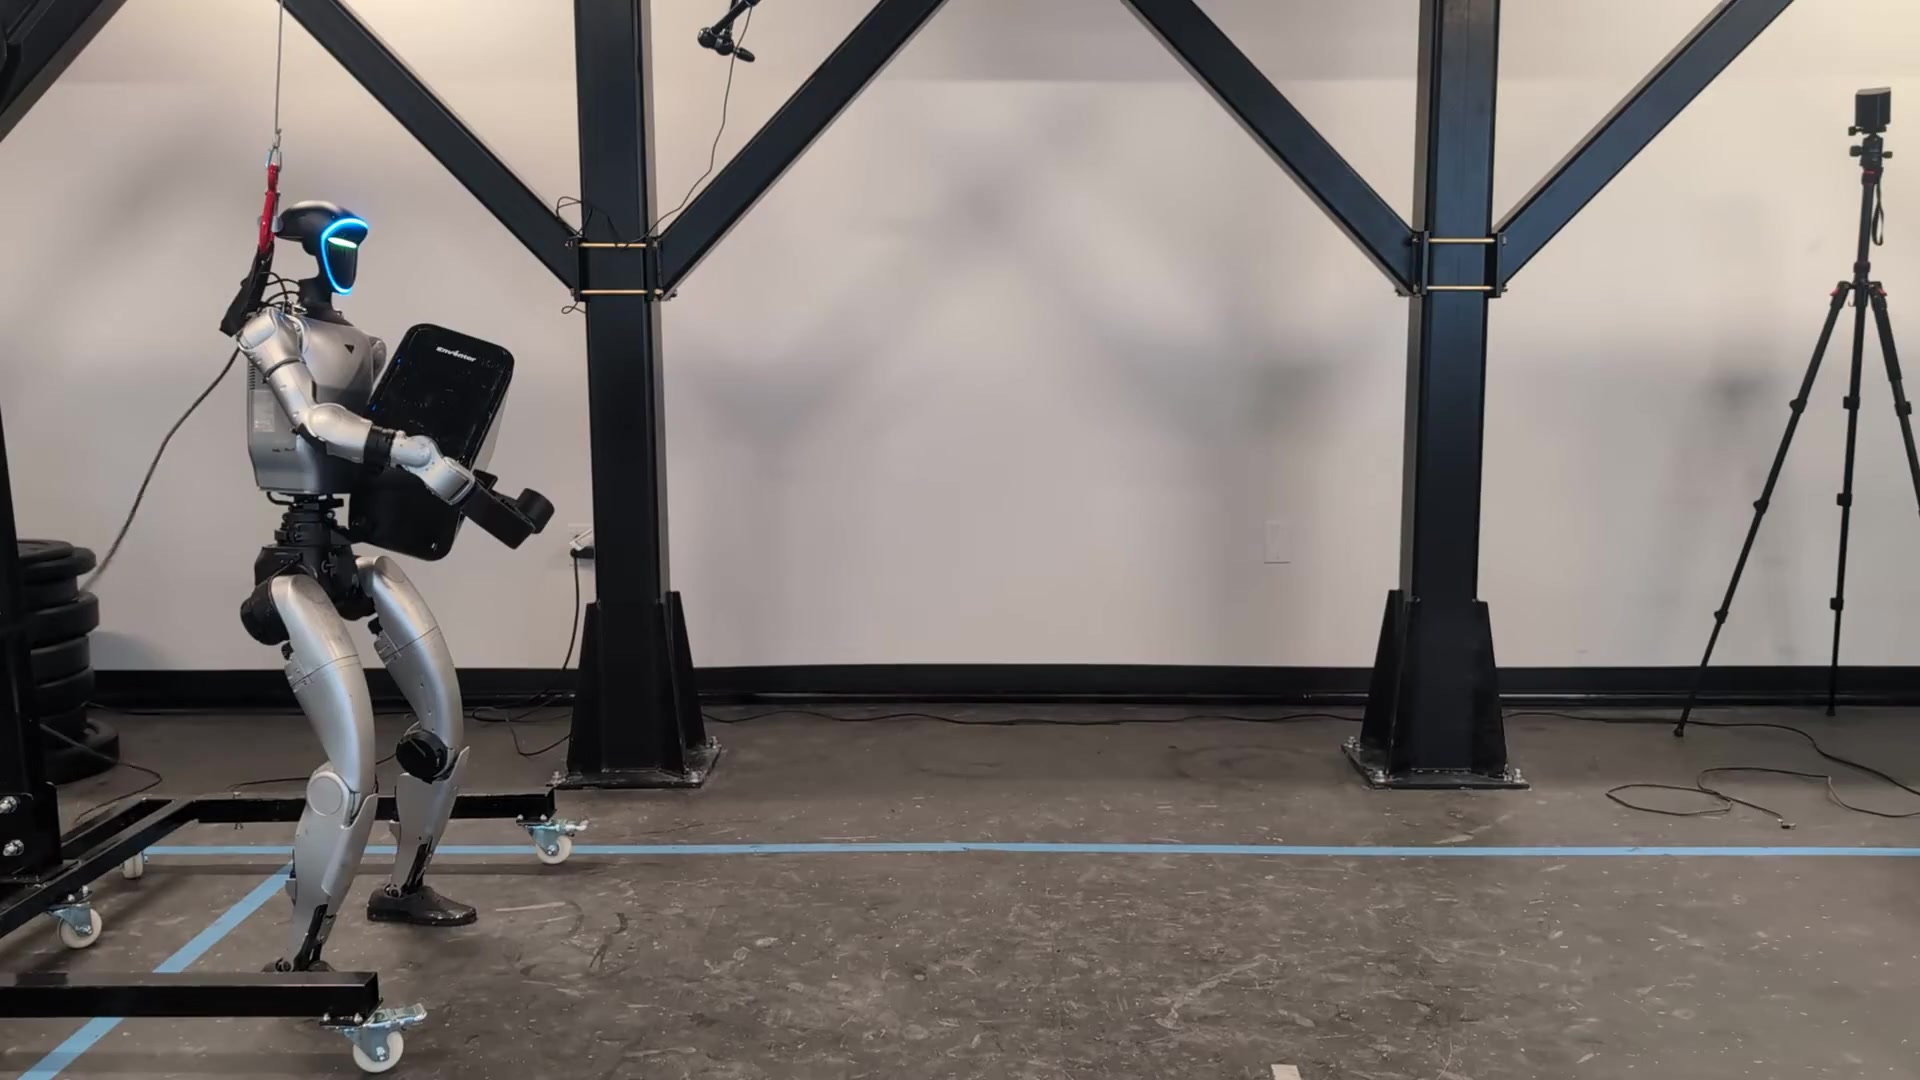
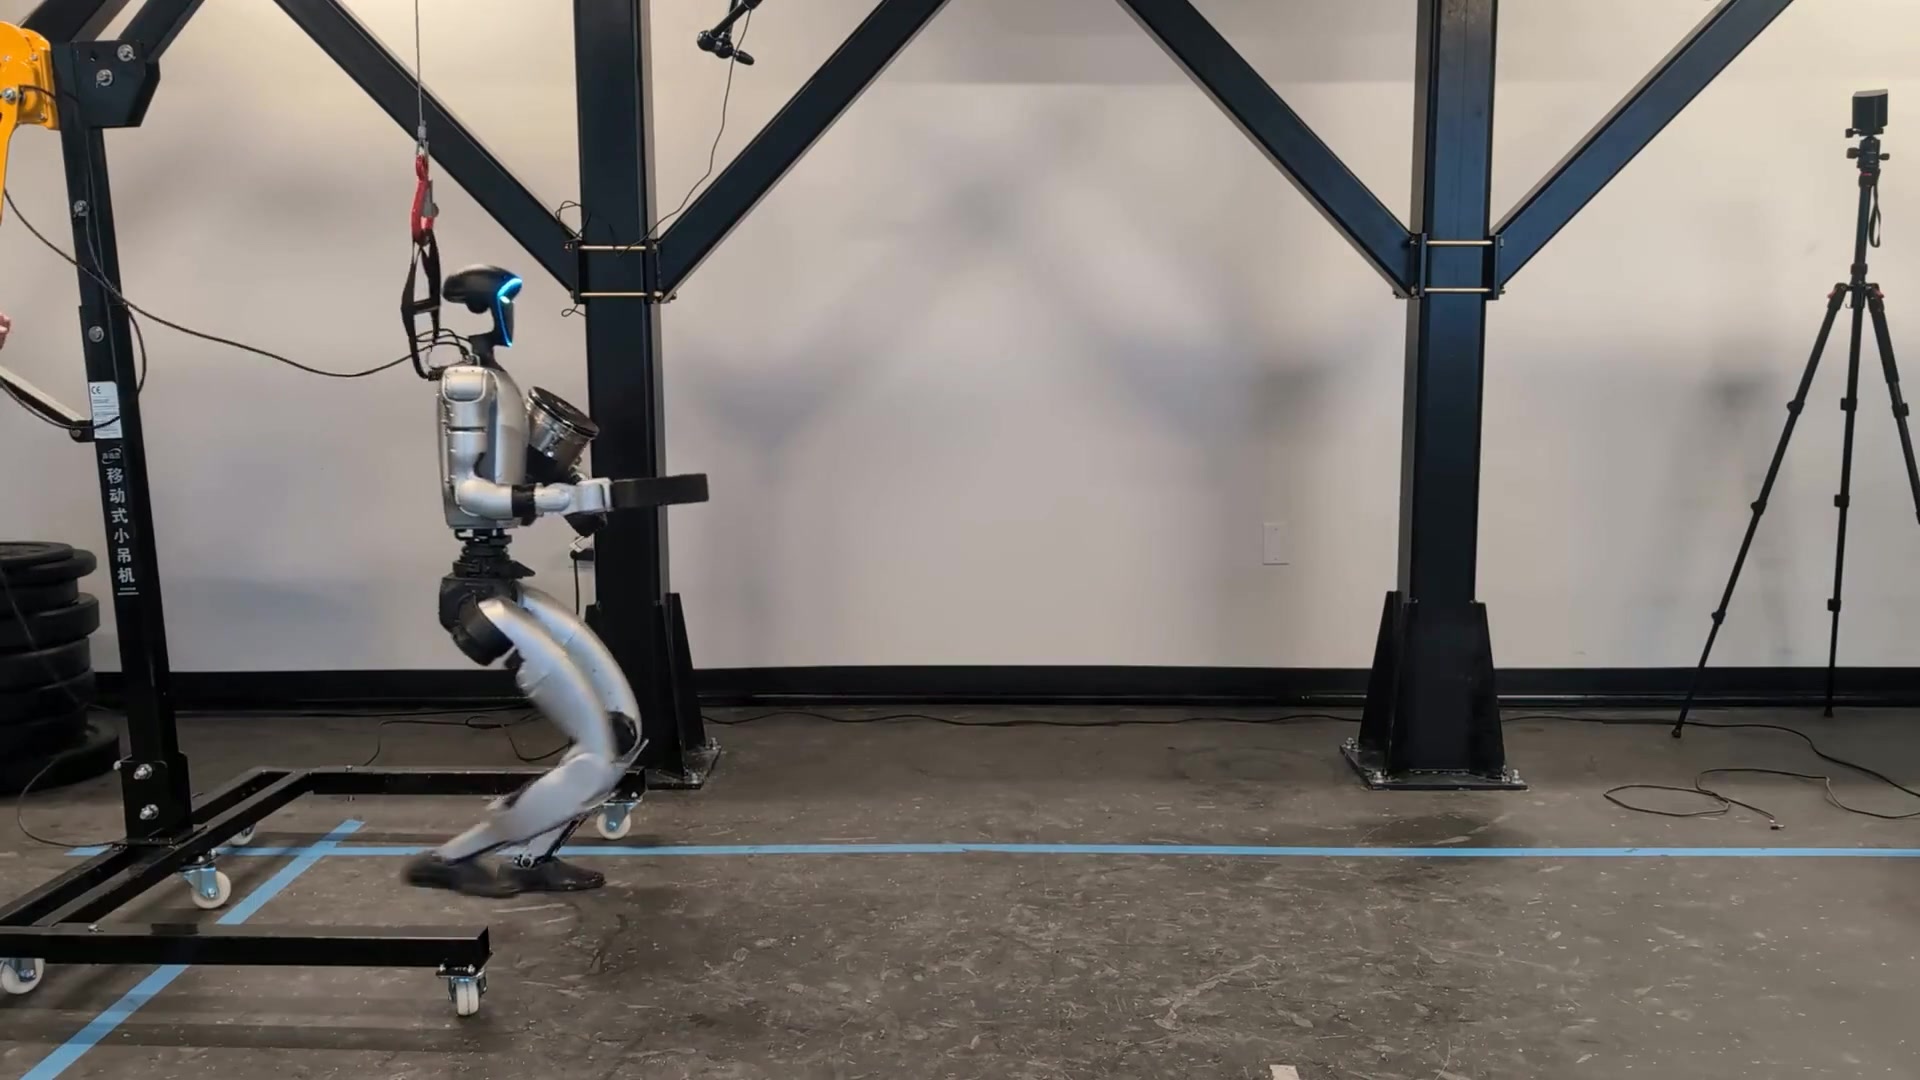
We benchmark against AMO, FALCON, and Thor on four real-world tasks: cart pulling, payload carrying, fridge carrying, and canister carrying.
Hardware highlight
300 kg cart pull
HULK pulls a 300 kg cart in the standalone hardware demonstration.
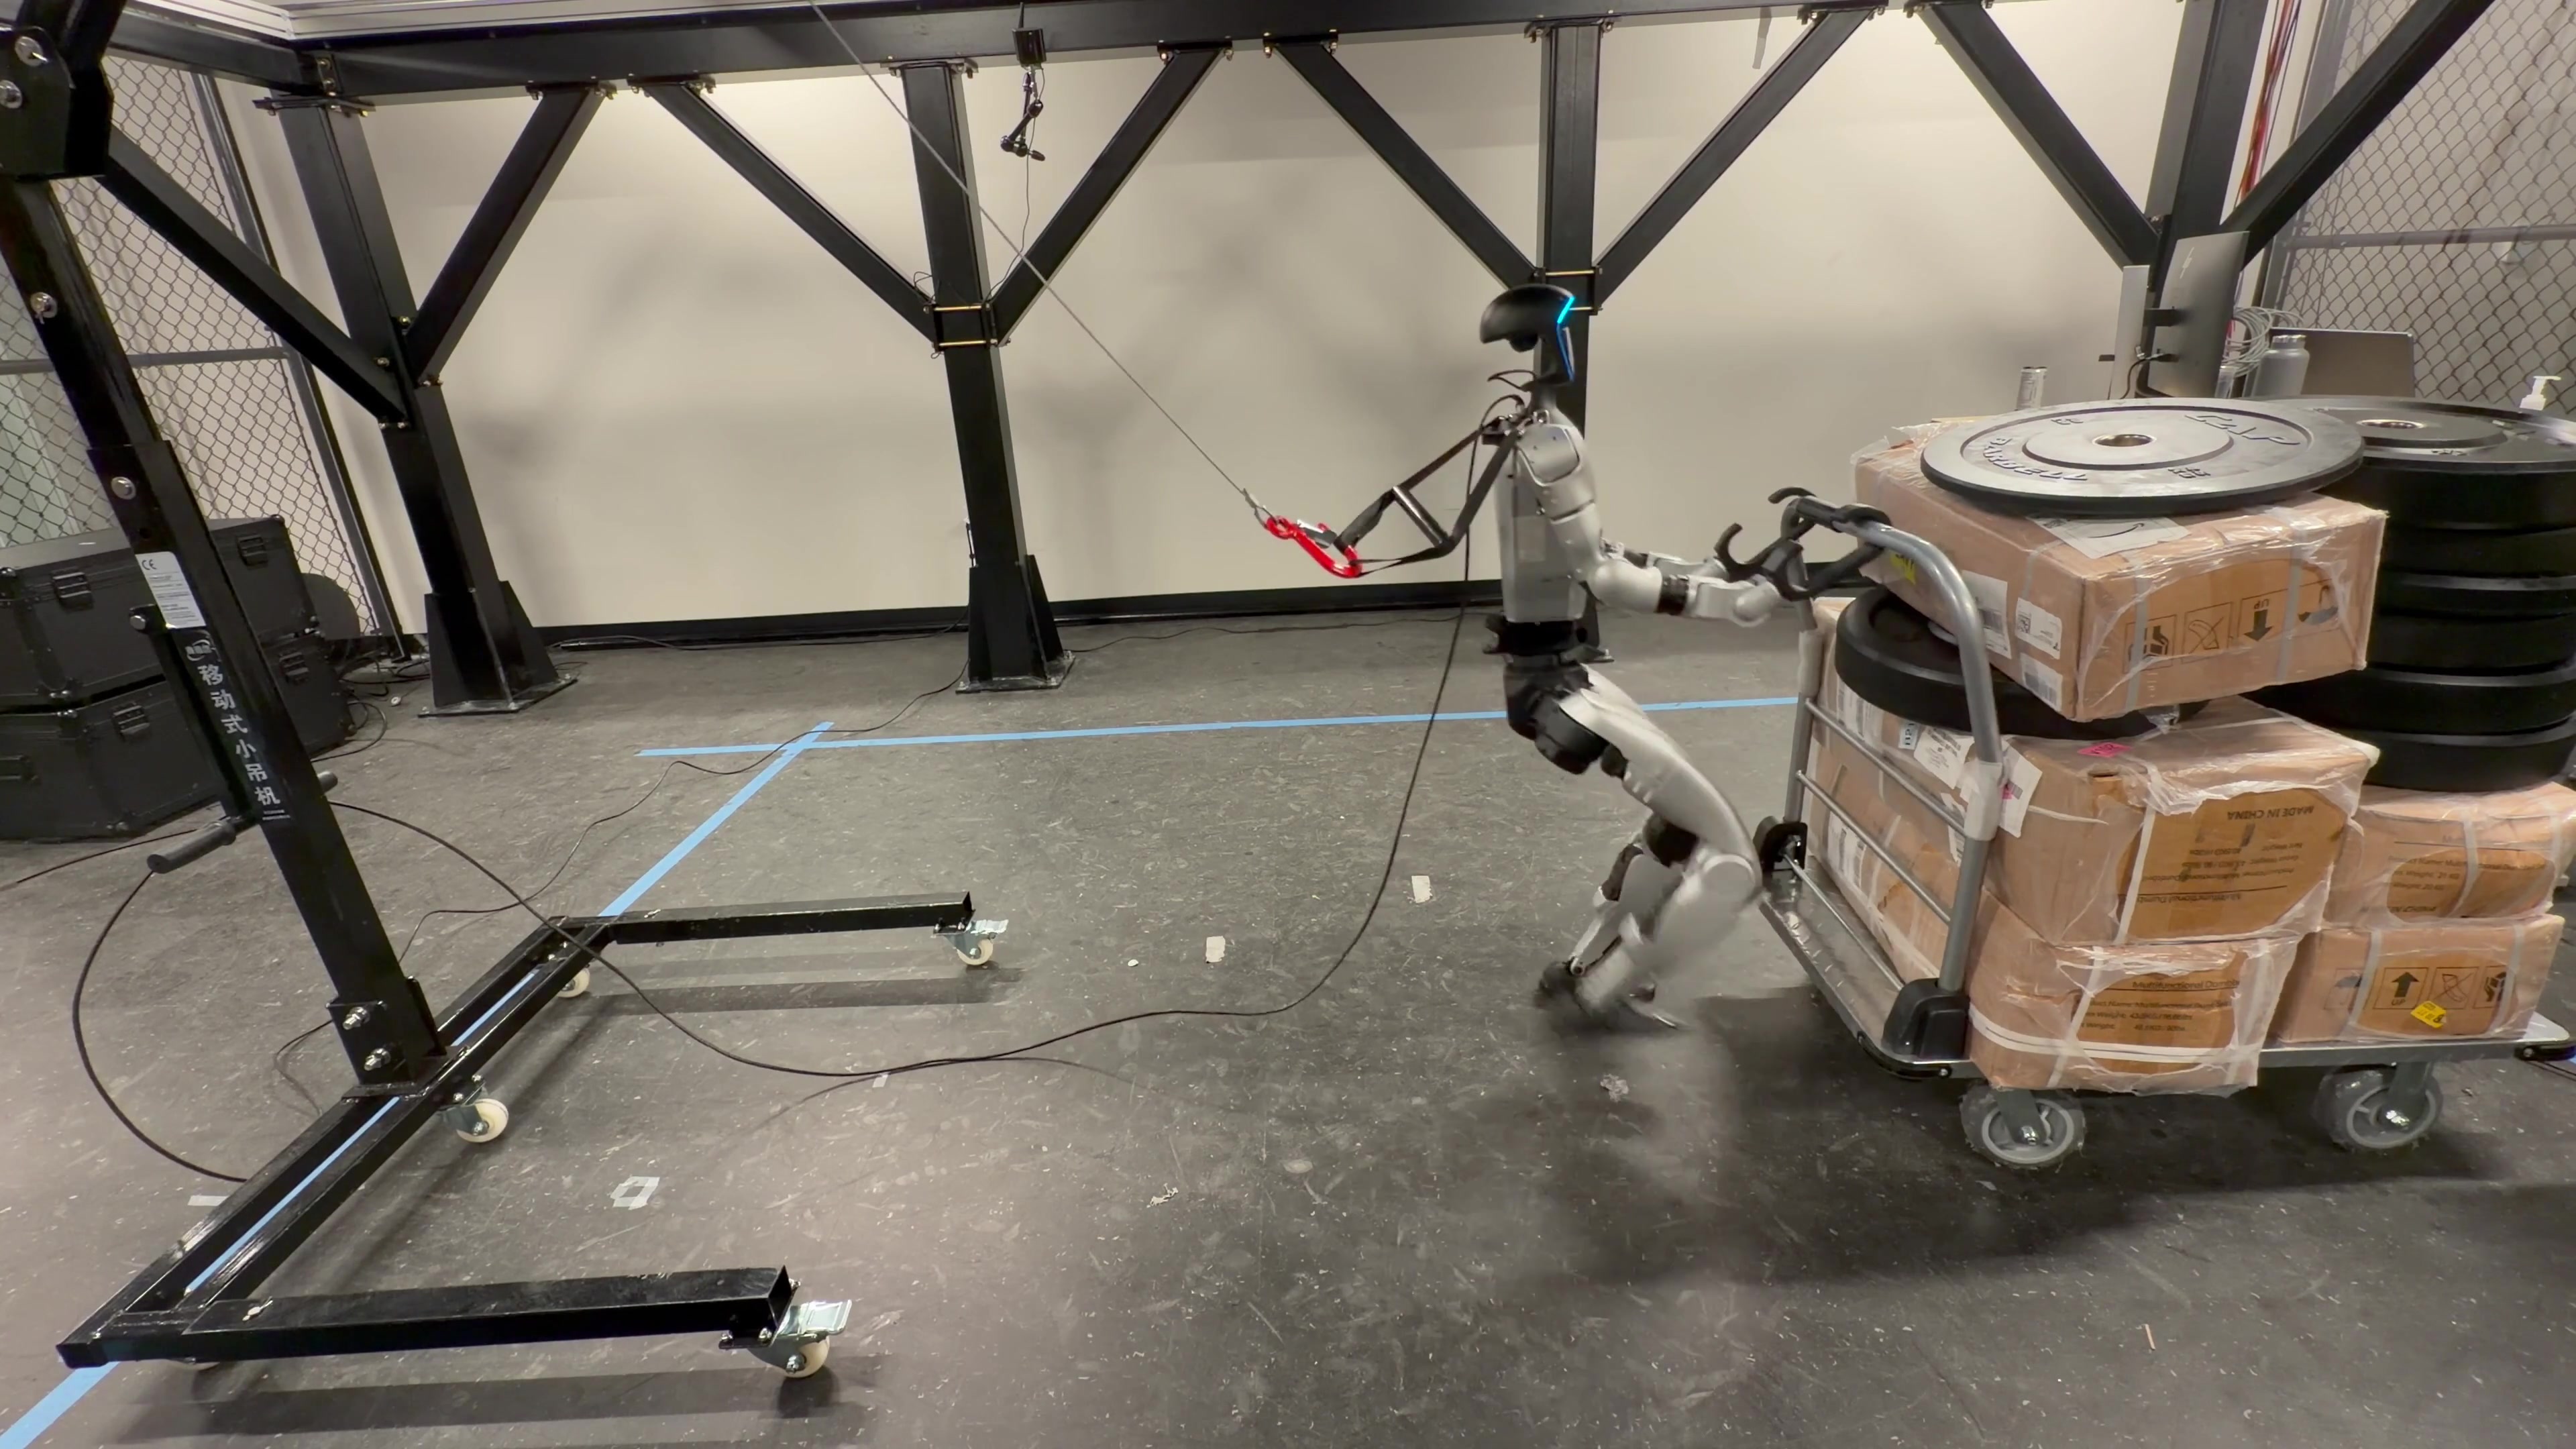
300 kg cart pull
The 300 kg value describes cart load, not pulling force; aggregate results are reported separately below.
Compare the clips side by side. Tap a video to enlarge it.
Cart Pulling
HULK (Ours)
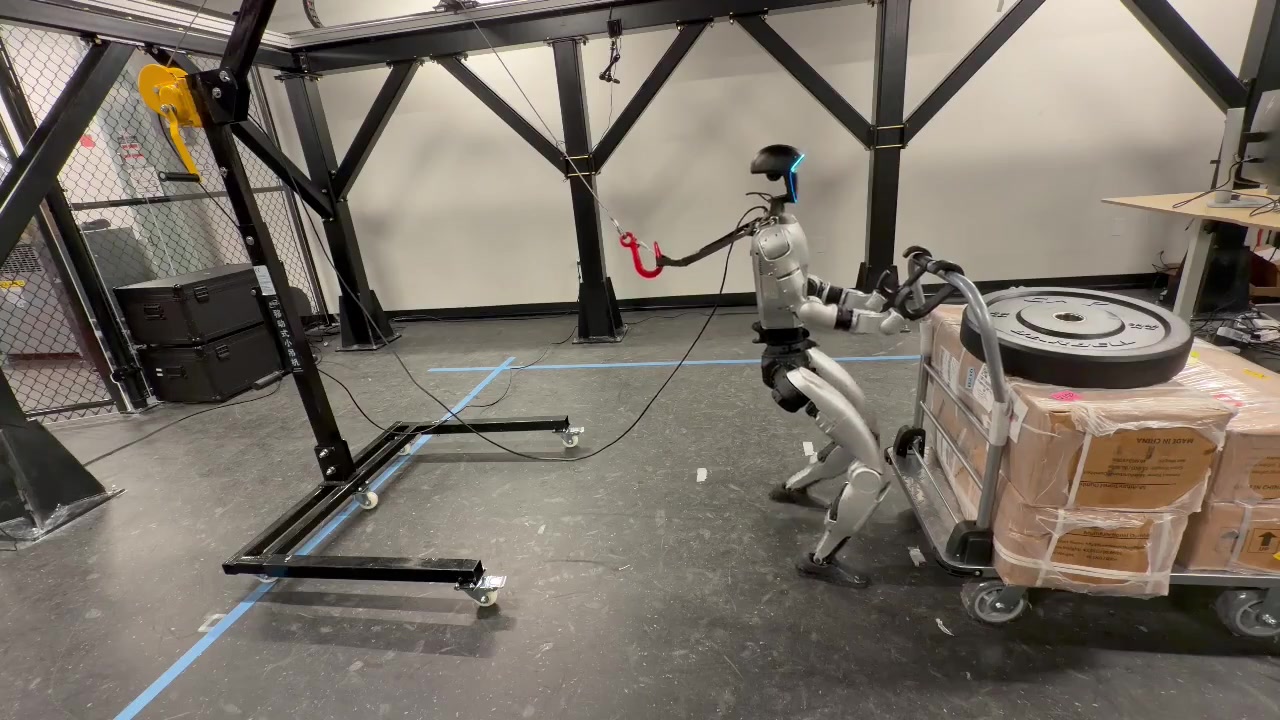
Cart Pulling
FALCON
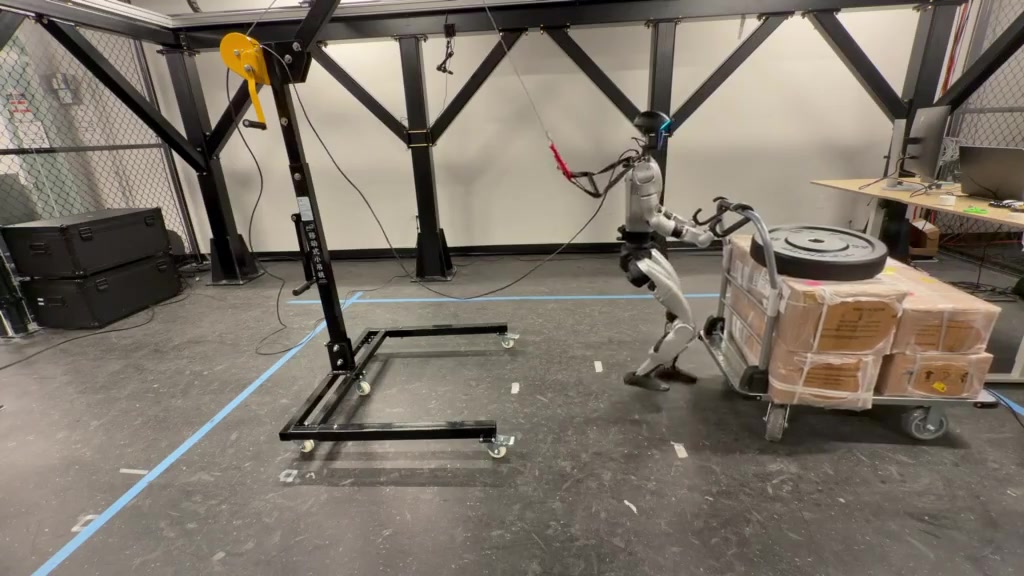
Cart Pulling
Thor
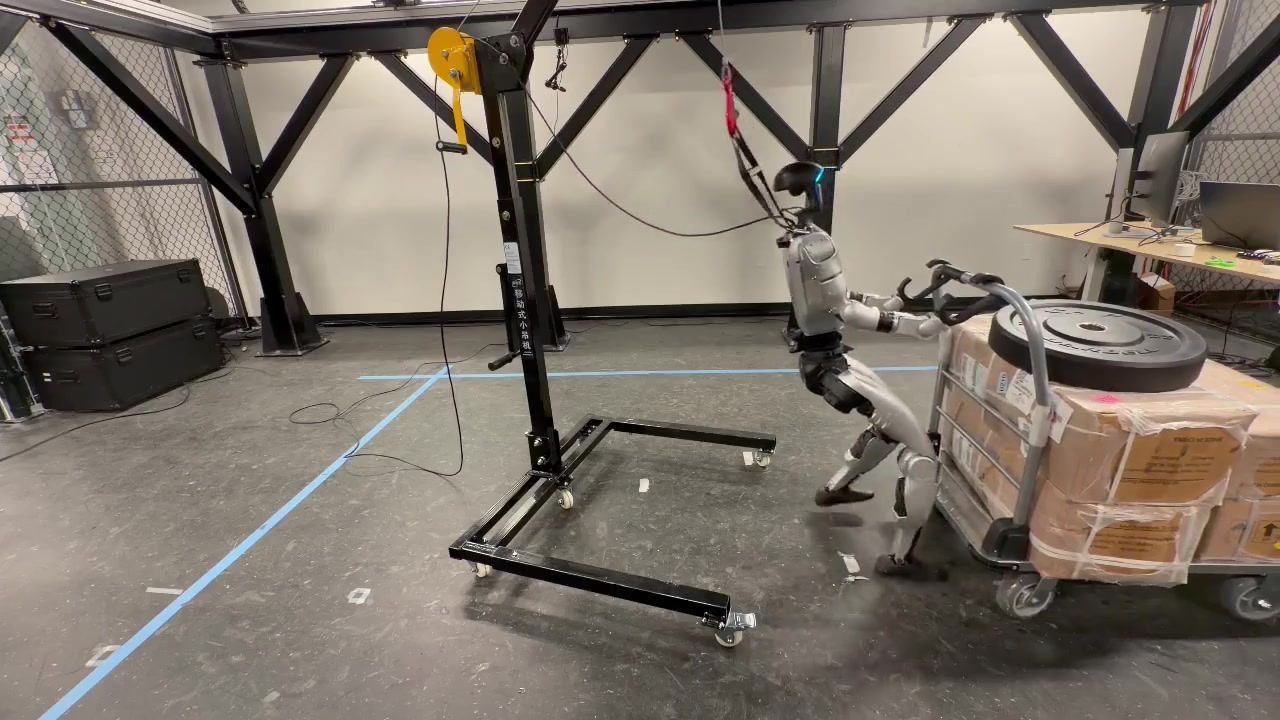
Cart Pulling
AMO
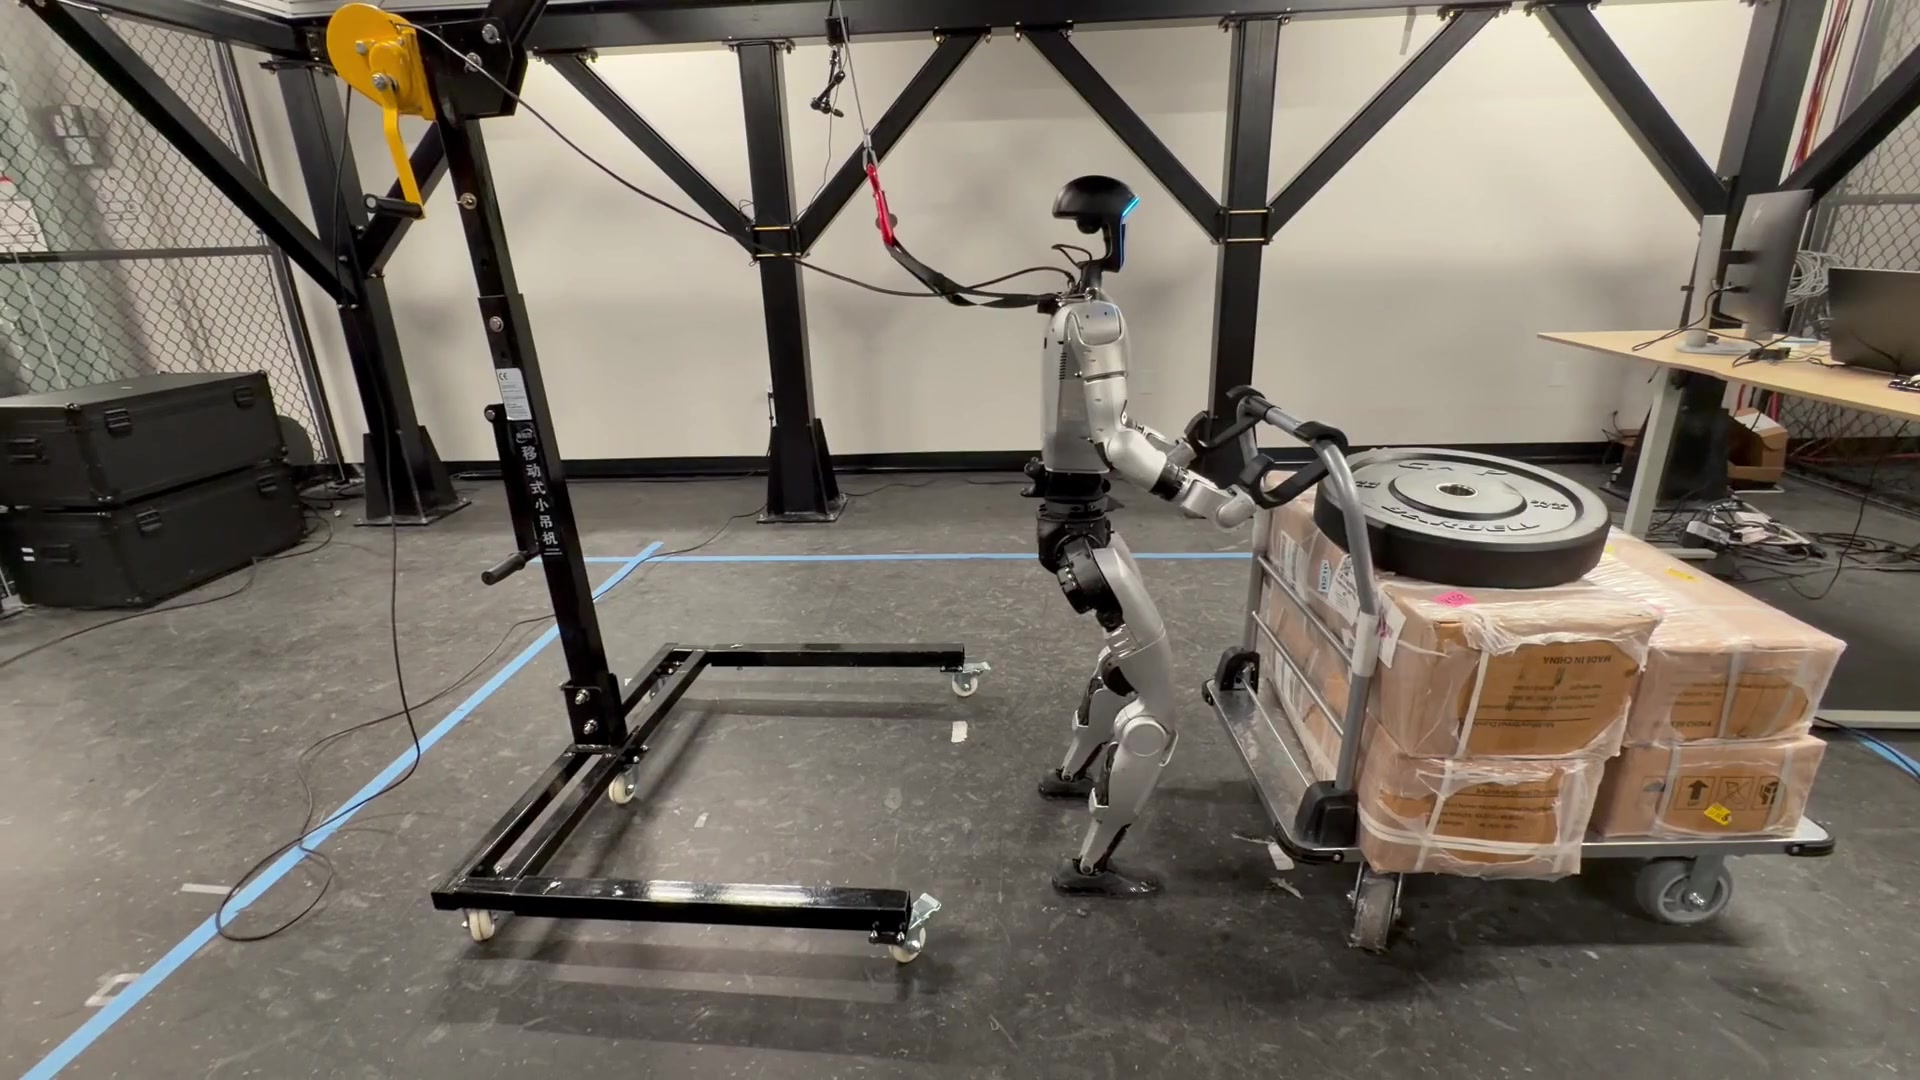
Cart Pulling
Payload Carrying
HULK (Ours)
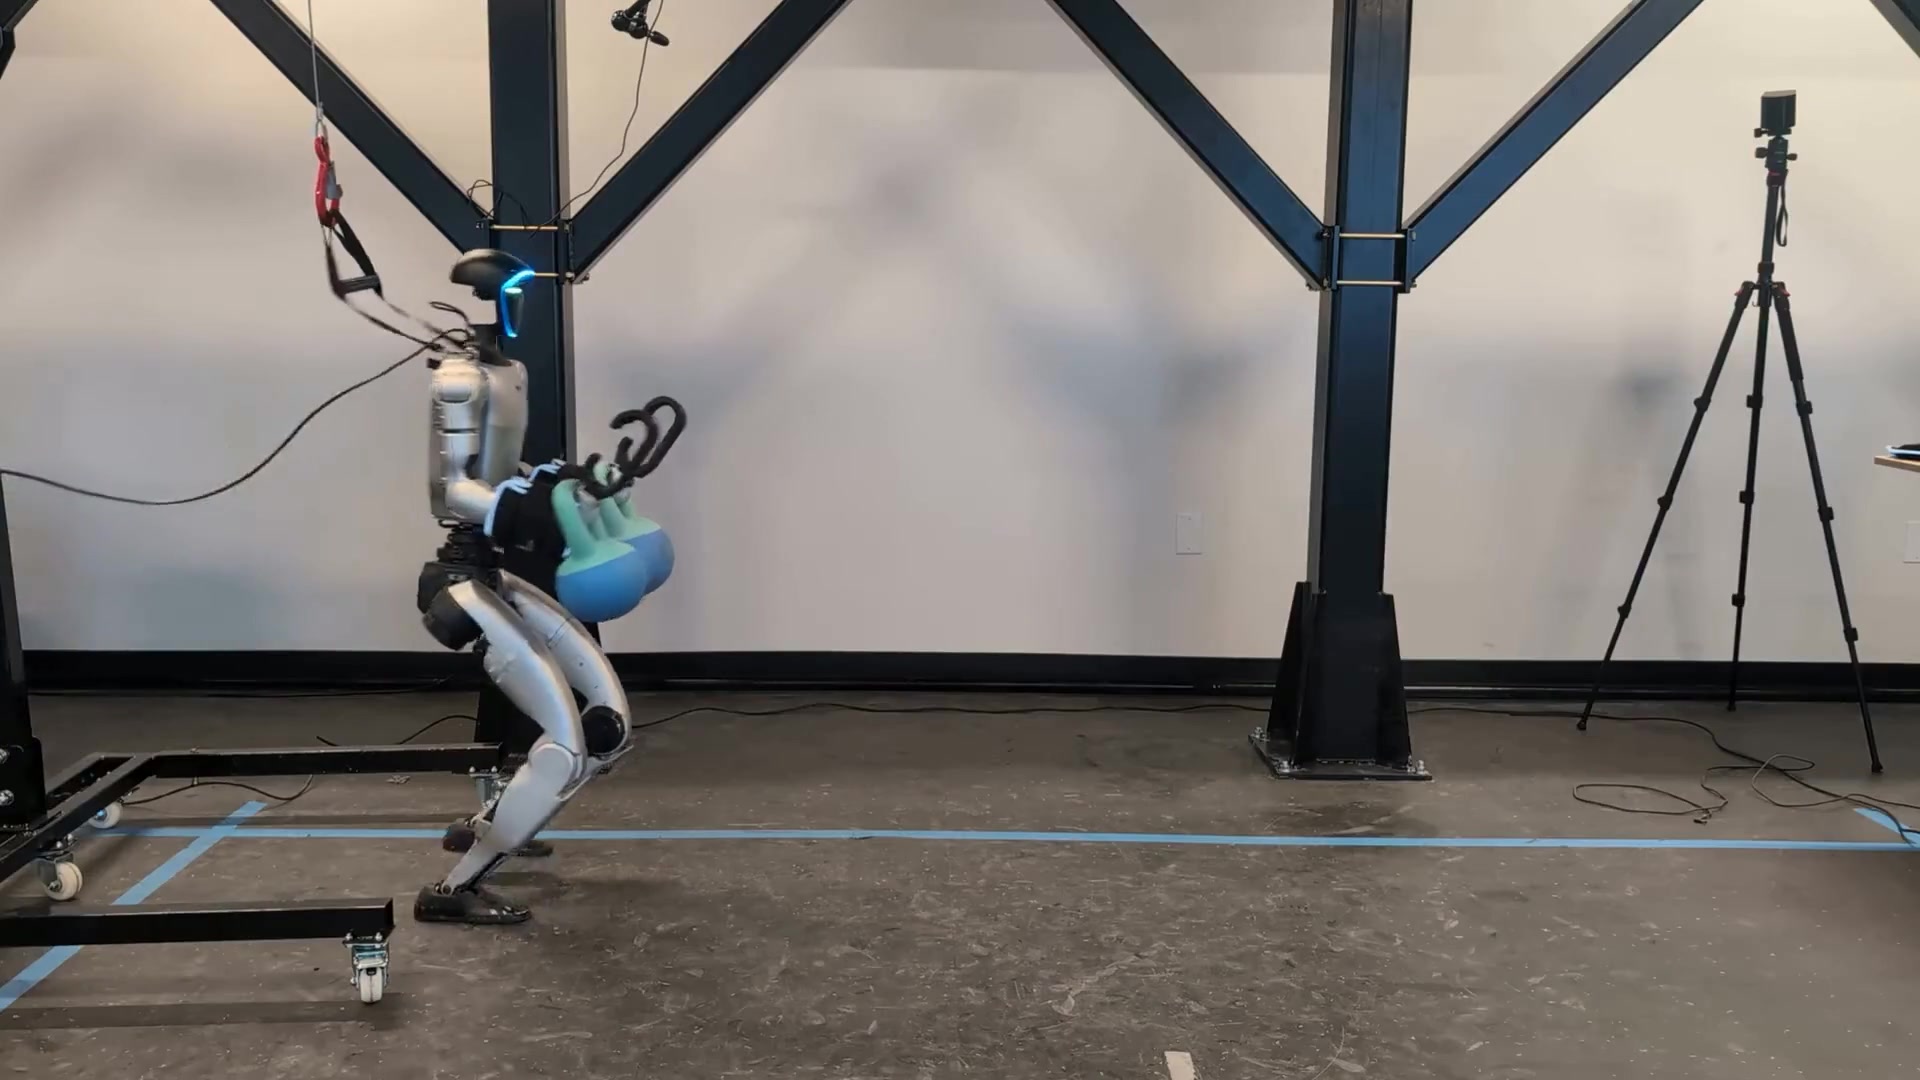
Payload Carrying
FALCON
Payload Carrying
Thor
Payload Carrying
AMO
Payload Carrying
Fridge Carrying
HULK (Ours)
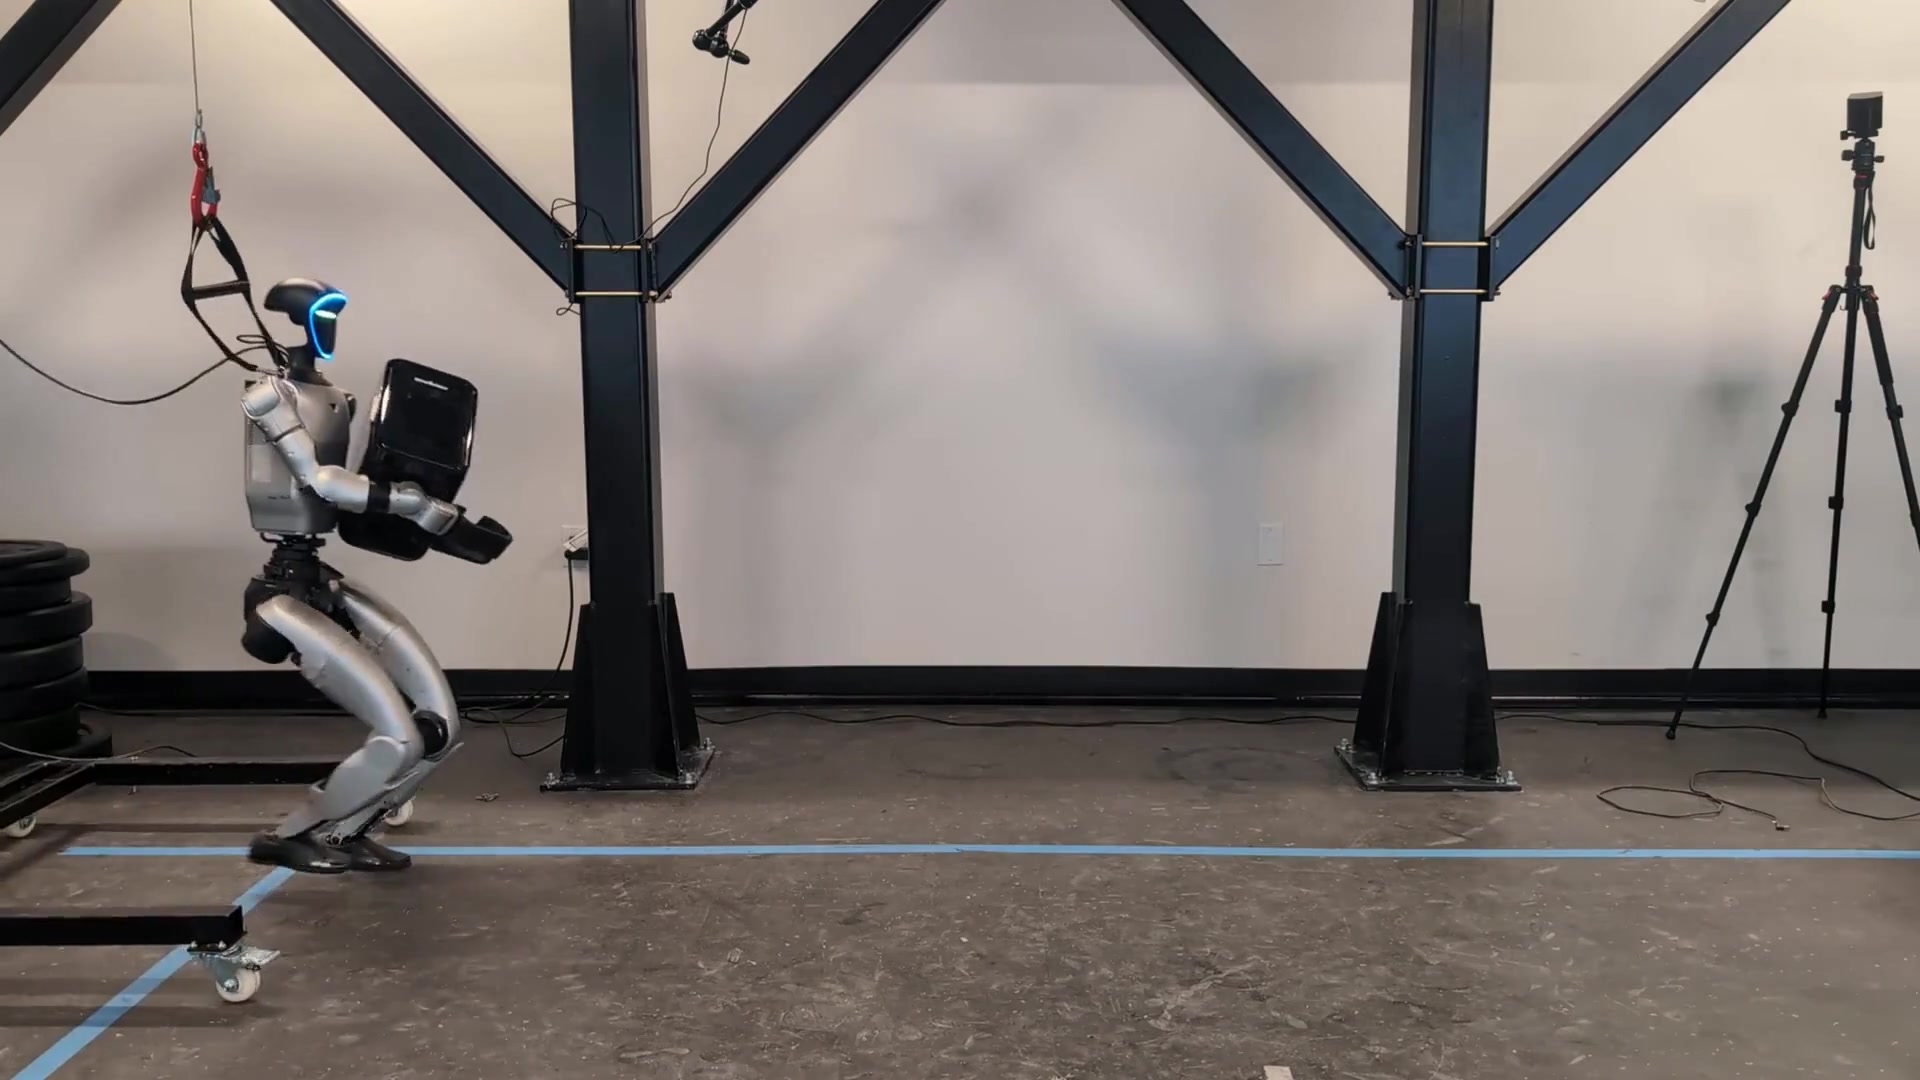
Fridge Carrying
FALCON
Fridge Carrying
Thor
Fridge Carrying
AMO
Fridge Carrying
Canister Carrying
HULK (Ours)
Canister Carrying
FALCON
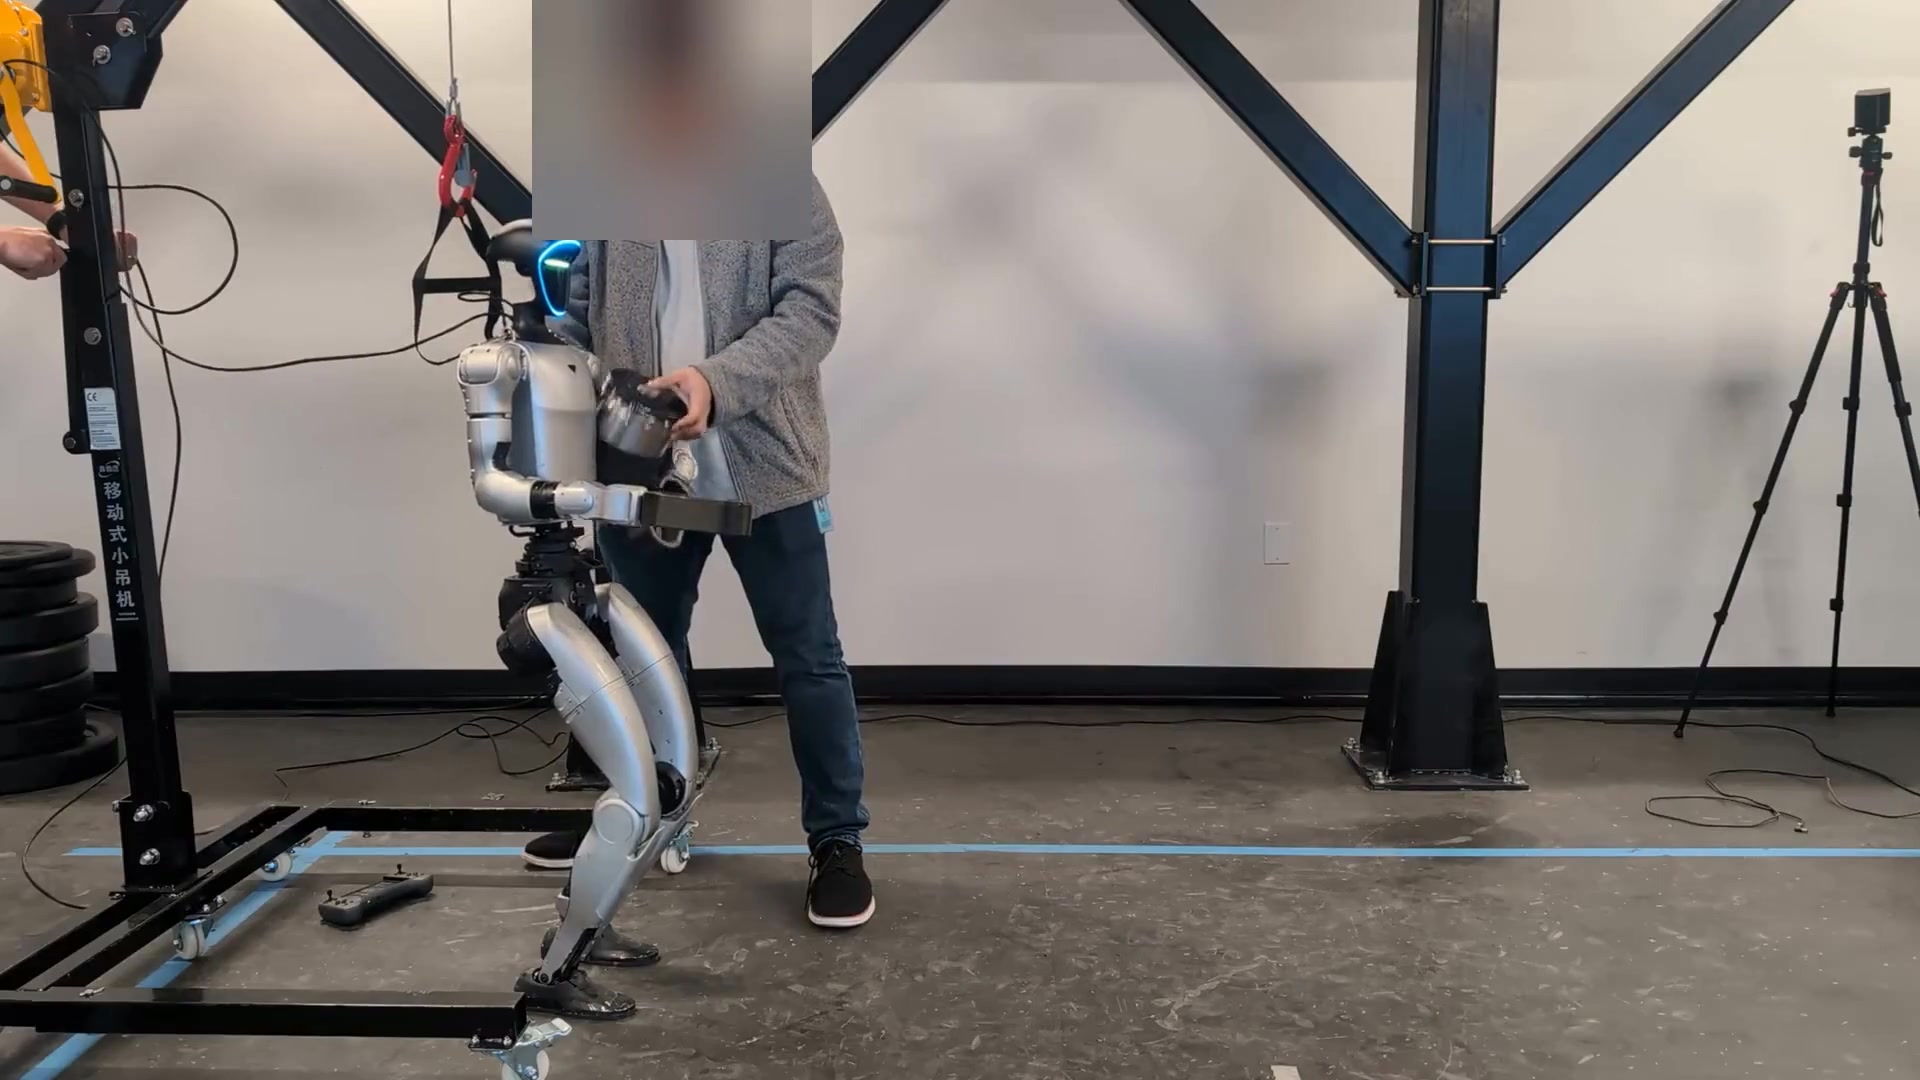
Canister Carrying
Thor
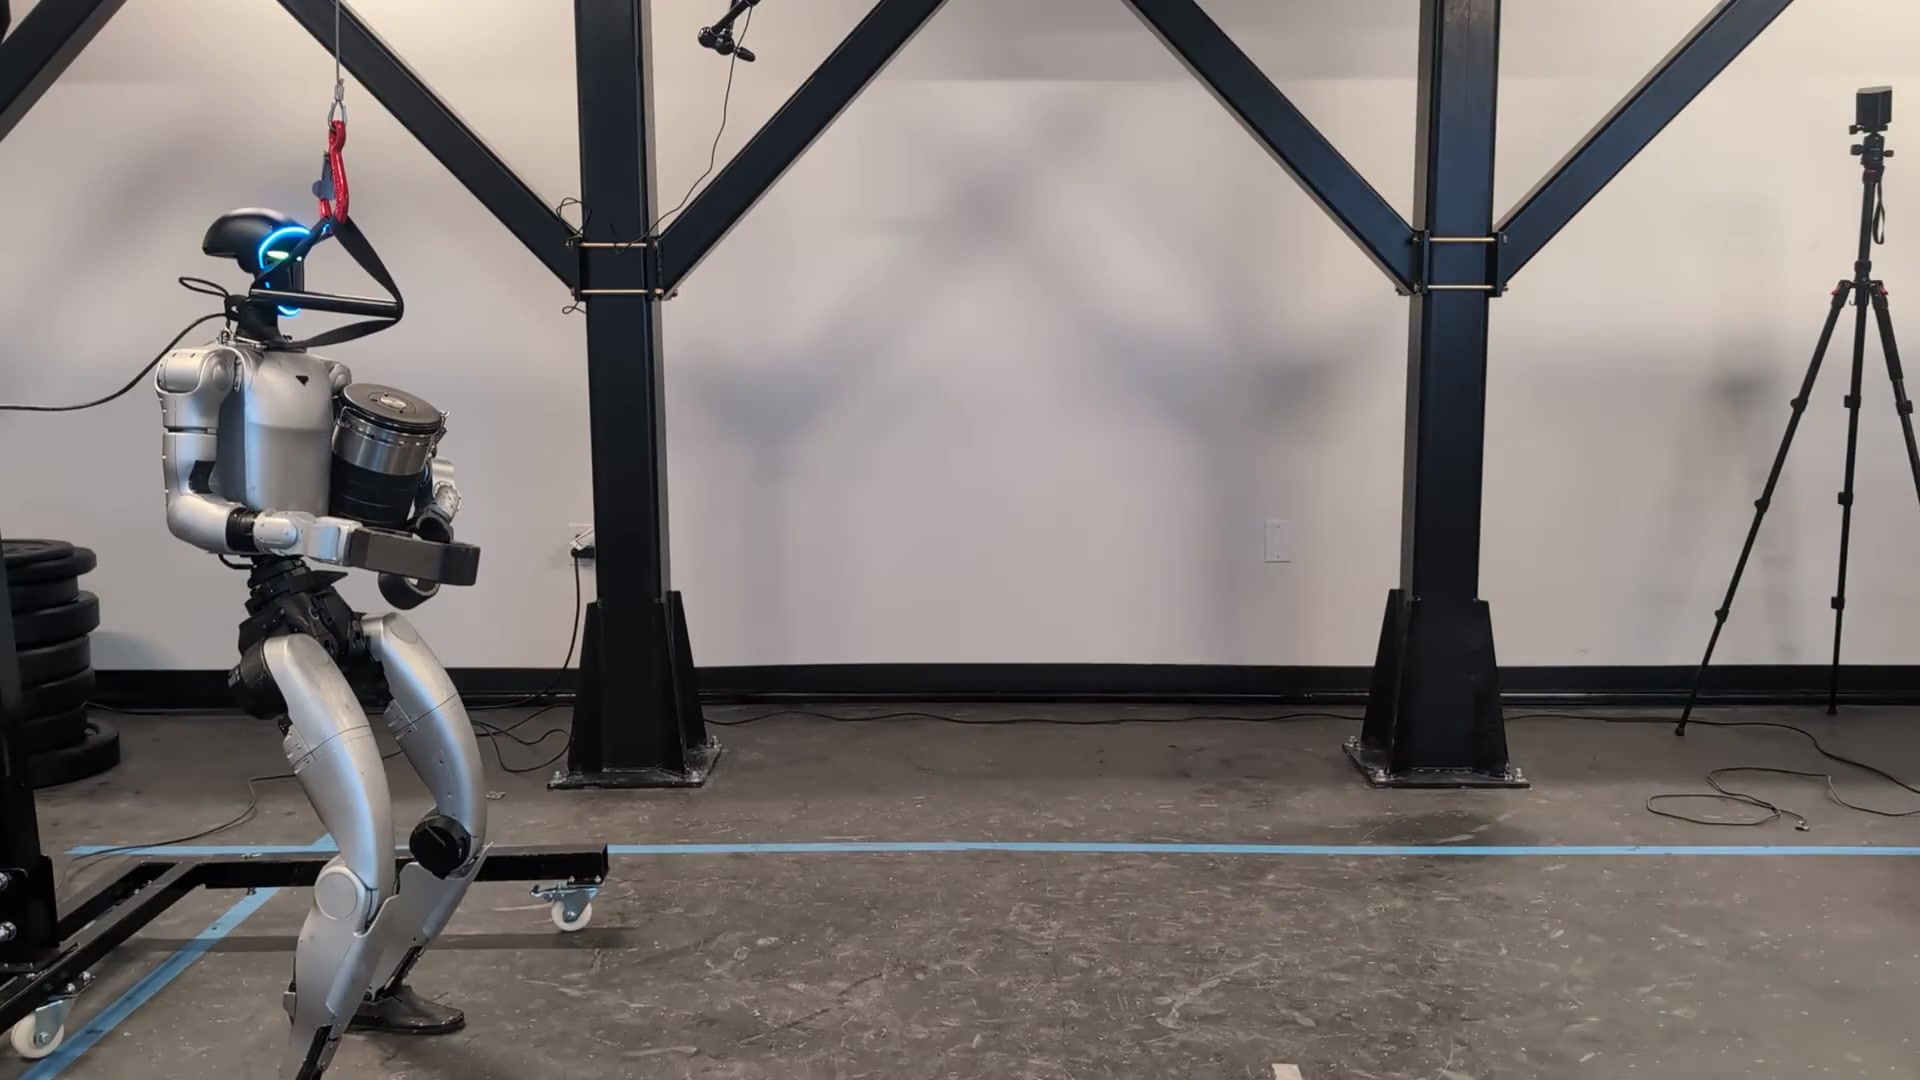
Canister Carrying
AMO
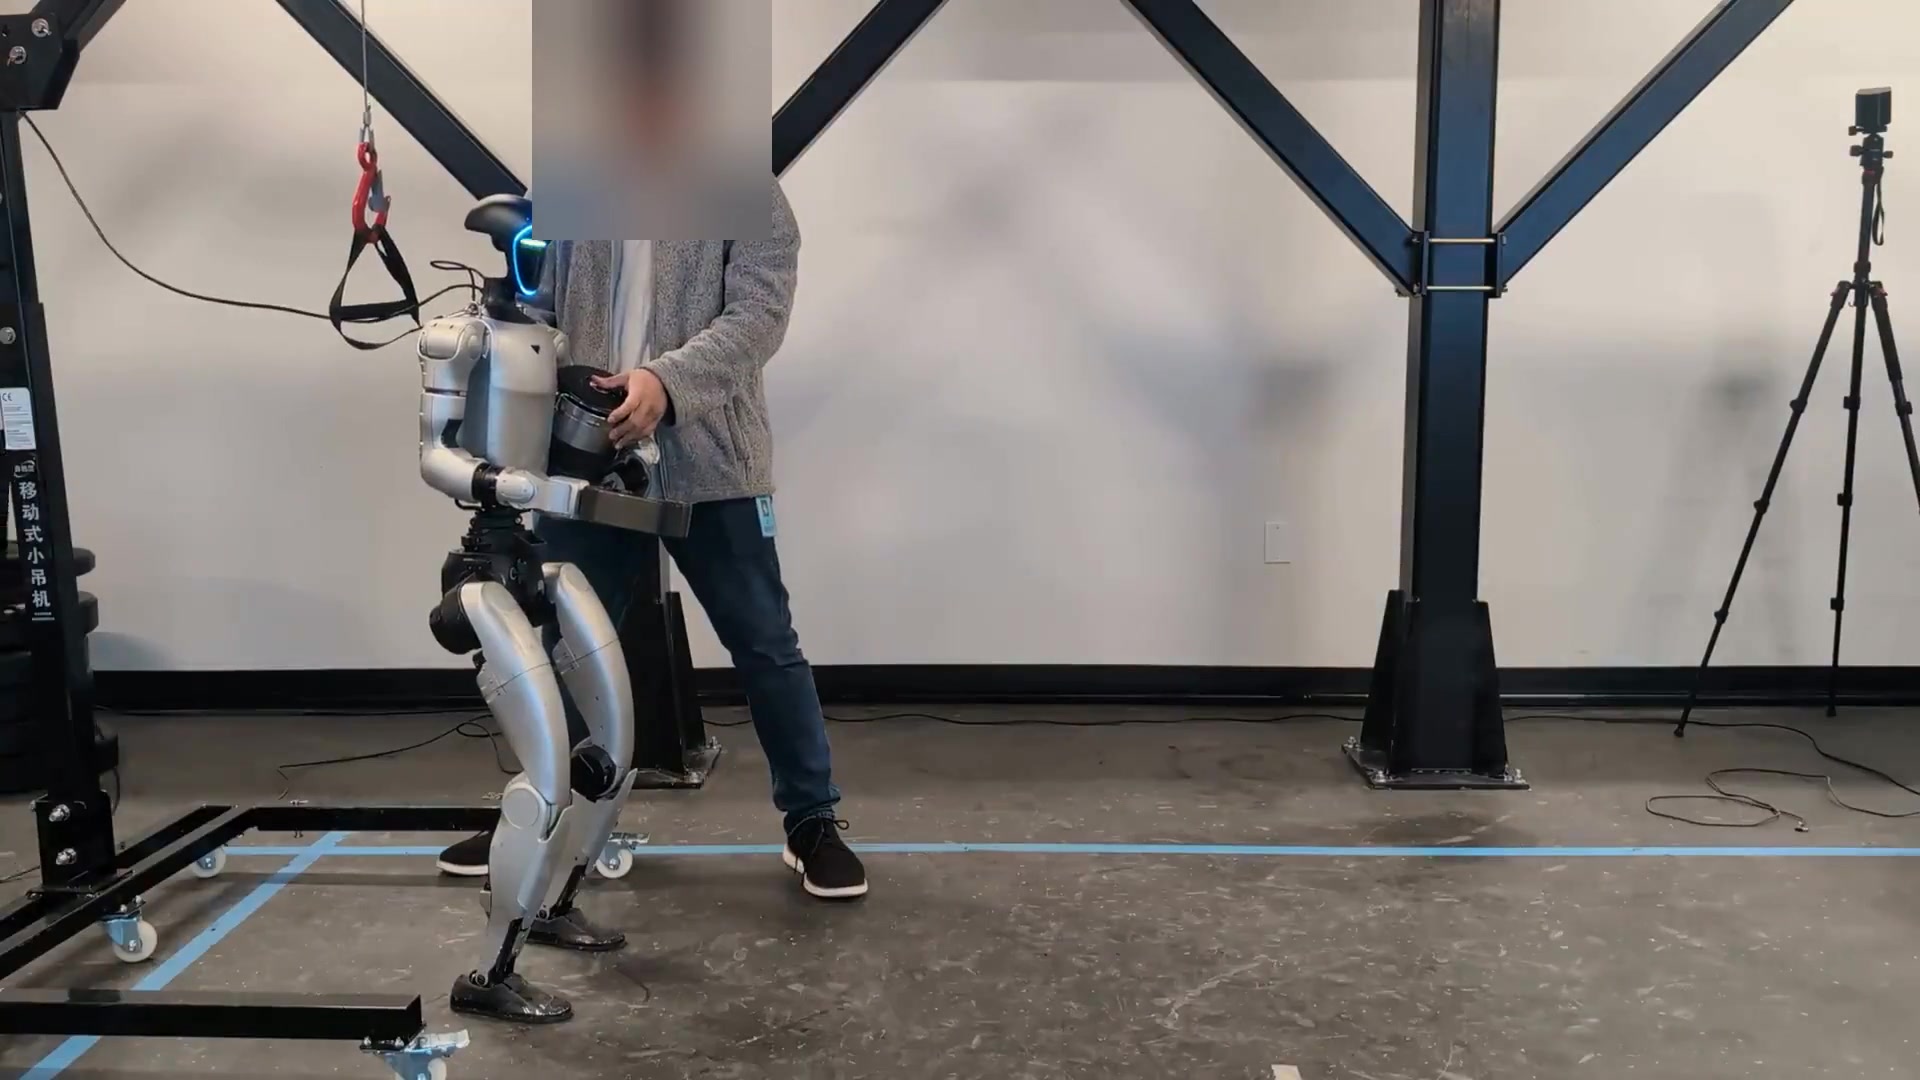
Canister Carrying
Benchmark Results
Carrying and disturbance rejection
This simulation benchmark measures walking-command tracking under 10 kg per arm and recovery from separate torso pushes, with mean ± standard deviation across five evaluation seeds. Our MPC-RL + DCM-CBF teacher has the lowest forward and lateral errors, smallest DCM excursions and peak tilt, and largest push survived, while AMO has the lowest mean turning error.
Swipe the table sideways to see all results.
| Method | Forward errorm/s ↓ | Lateral errorm/s ↓ | Turn-rate errorrad/s ↓ | Signed DCM marginm ↑ | Peak tilt · 50 Ndeg ↓ | Maximum pushN ↑ |
|---|---|---|---|---|---|---|
| Thor | 0.263 ± 0.002 | 0.265 ± 0.003 | 0.450 ± 0.006 | -0.275 ± 0.016 | 23.17 ± 0.13 | 80 |
| AMO | 0.276 ± 0.002 | 0.350 ± 0.004 | 0.196 ± 0.003 | -0.705 ± 0.030 | 9.94 ± 0.74 | 50 |
| FALCON | 0.367 ± 0.012 | 0.369 ± 0.013 | 0.392 ± 0.005 | -0.329 ± 0.034 | 7.91 ± 0.23 | 80 |
| Ours (MPC-RL) | 0.242 ± 0.009 | 0.257 ± 0.004 | 0.234 ± 0.008 | -0.251 ± 0.011 | 5.90 ± 0.18 | 110 |
| Ours + DCM-CBF | 0.210 ± 0.007 | 0.142 ± 0.003 | 0.197 ± 0.009 | -0.162 ± 0.012 | 5.59 ± 0.24 | 130 |
Real-world task performance
This Unitree G1 benchmark reports successful trials at a shared task load and the maximum load completed in all three trials of a separate sweep. Our distilled HULK student leads on cart pulling, fridge carrying, and canister carrying, and ties AMO on payload carrying.
Swipe the table sideways to see all results.
| Method | Cart push/pullTrials at 150 kg | Payload carryTrials at 11 kg | Fridge carryTrials at 6 kg | Canister carryTrials at 5 kg | ||||
|---|---|---|---|---|---|---|---|---|
| Completed ↑ | Max load · kg ↑ | Completed ↑ | Max load · kg ↑ | Completed ↑ | Max load · kg ↑ | Completed ↑ | Max load · kg ↑ | |
| Thor | 2/6 | 130 | 2/4 | 7.25 | 0/4 | 2 | 0/4 | 0.6 |
| AMO | 0/6 | 75 | 4/4 | 12.25 | 2/4 | 6 | 0/4 | 2.6 |
| FALCON | 3/6 | 200 | 0/4 | 3.62 | 0/4 | 2.5 | 0/4 | 0 |
| HULK | 5/6 | 300 | 4/4 | 12.25 | 4/4 | 7 | 4/4 | 6.1 |
BibTeX
@misc{hulk2026,
  title  = {HULK: Learning Whole-Body Forceful
            Loco-Manipulation for Humanoids},
  author = {Dang, An and Flores Alvarez, Arturo and Chen, Yu-Ming
            and Mc Gartoll, Conor and Sun, Helen and Ames, Aaron
            and Fazeli, Nima and Nambi, Manikantan},
  year   = {2026},
  eprint = {2610.08970},
  archivePrefix = {arXiv},
  url    = {https://arxiv.org/abs/2610.08970}
}
arXiv preprint, 2026.